Hydrophone Progress- 9/13/26
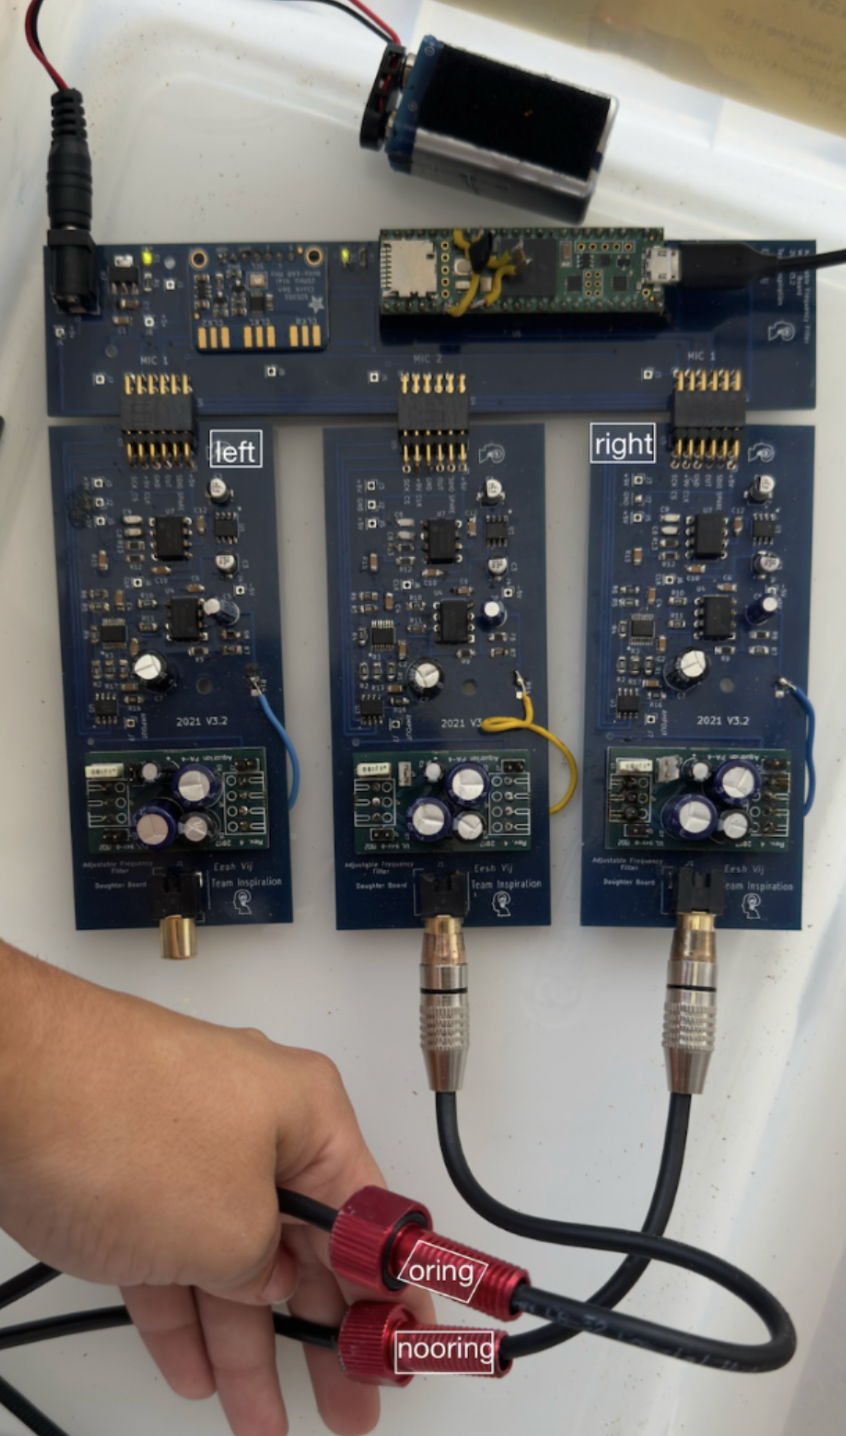
Our sub locates the RobotX pinger with a set of three hydrophones, listening for timing differences between them to tell which direction it's coming from. The board we'd been using for that was inherited from a previous team: three separate daughterboards, one per hydrophone channel.
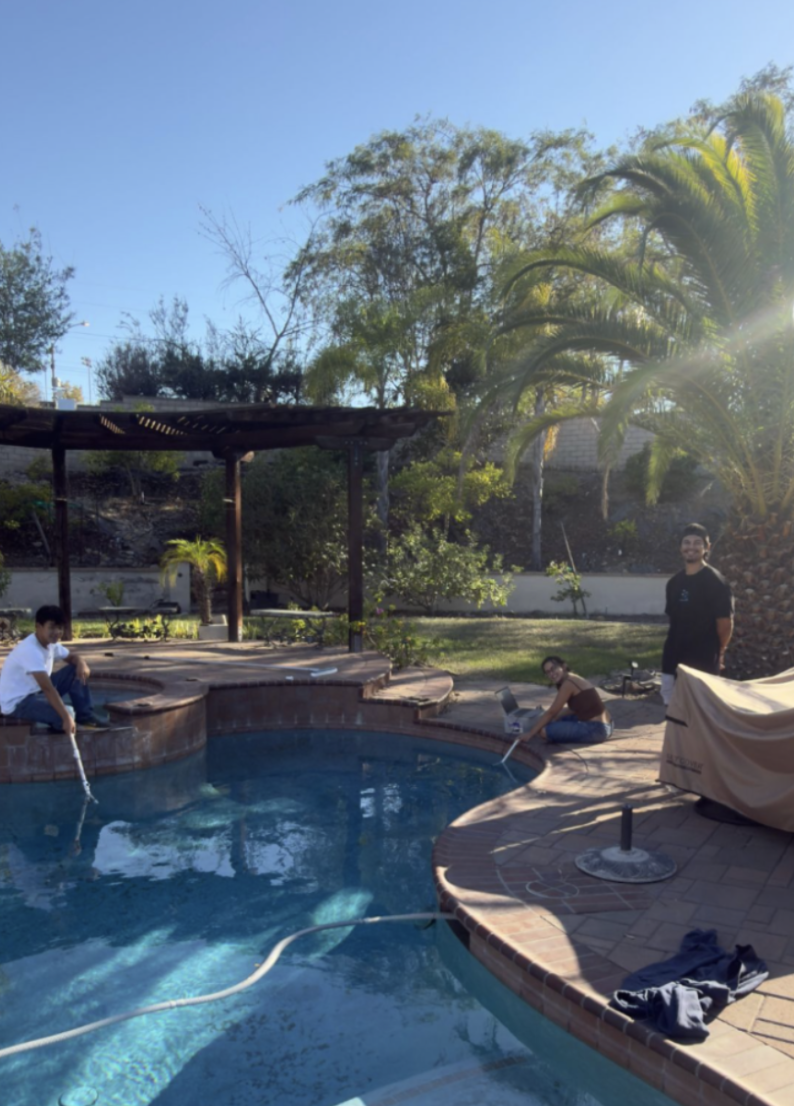
Back in August we ran a round of pool tests on it, checking two of our hydrophones (nicknamed Oring and Nooring) against all three daughterboards. Turned out the hydrophones themselves were fine, but two of the three daughterboards weren't: the middle one had corroded, and the right one had flux residue and a partially cut component. Only the left board gave clean readings for both hydrophones. Combined with some other issues in the original design (noisy connectors between the boards, an op-amp not well suited to our hydrophones), we decided it was time for a full redesign instead of patching around it.
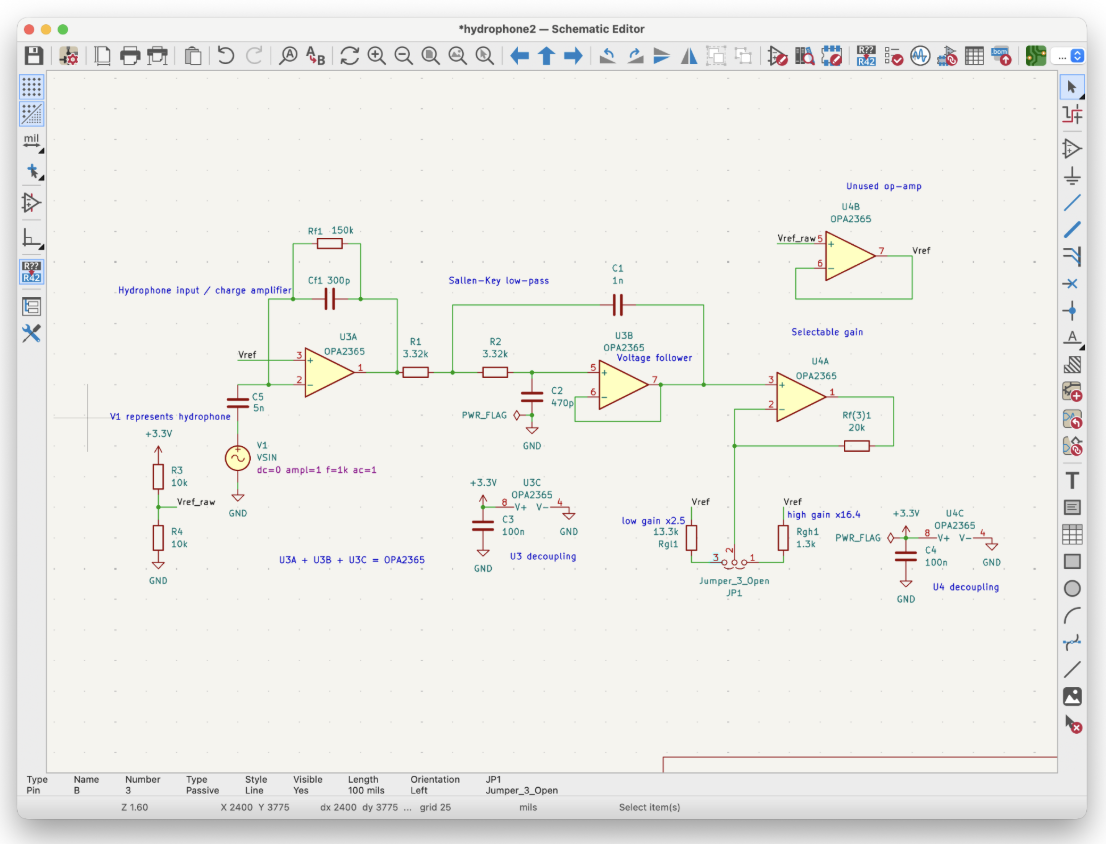
The new design puts all three channels through a charge amp, filter, and gain stage on one consolidated board, feeding a Teensy 4.1 for the timing math, small enough to fit inside a Blue Robotics tube. The schematic is done in KiCad and the wiring's been checked. Aquarian Audio (our hydrophone supplier) sent over real capacitance numbers for our units, which we're now using to recalculate the gain stage before it goes out for review. Next: PCB layout, then bench and pool testing on the new board.