
Boat (USV)
RobotX 2026 > Boat
Overview
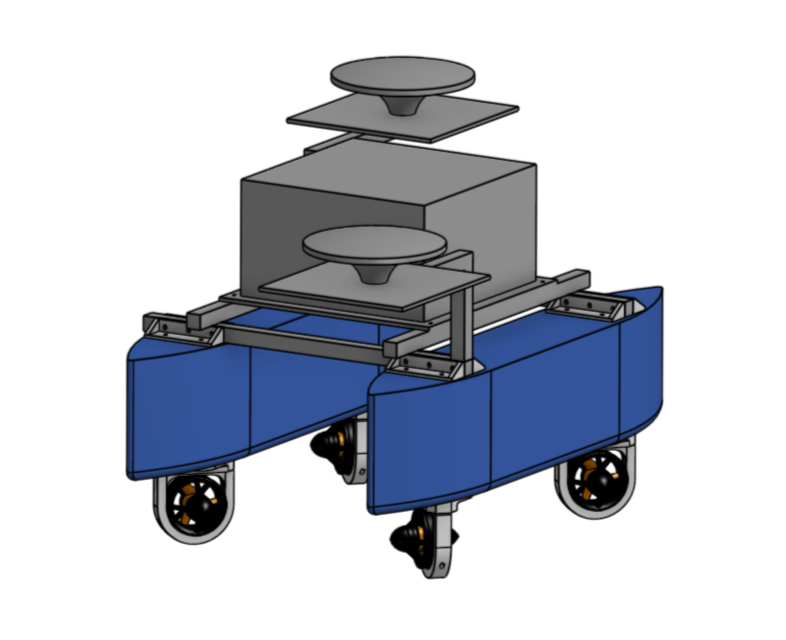
Our RobotX Boat, Crusader, features a catamaran configuration with a flat-bottom hull, which is ideally suited for calm and shallow-water navigation, thereby optimizing stability and maneuverability. With a focus on cost-effectiveness, ease to build, durability and proven construction method, we reused materials from previous competitions, including spare wood and high-density foam. Once we formed our foam hull, wood boards were added to the top and bottom for stiffness. Fiberglass was added with resin to strengthen the body. The boat is finished with paint to waterproof the hull(s) and aesthetic. Blue is the color of our team and the planet earth.
Crusader
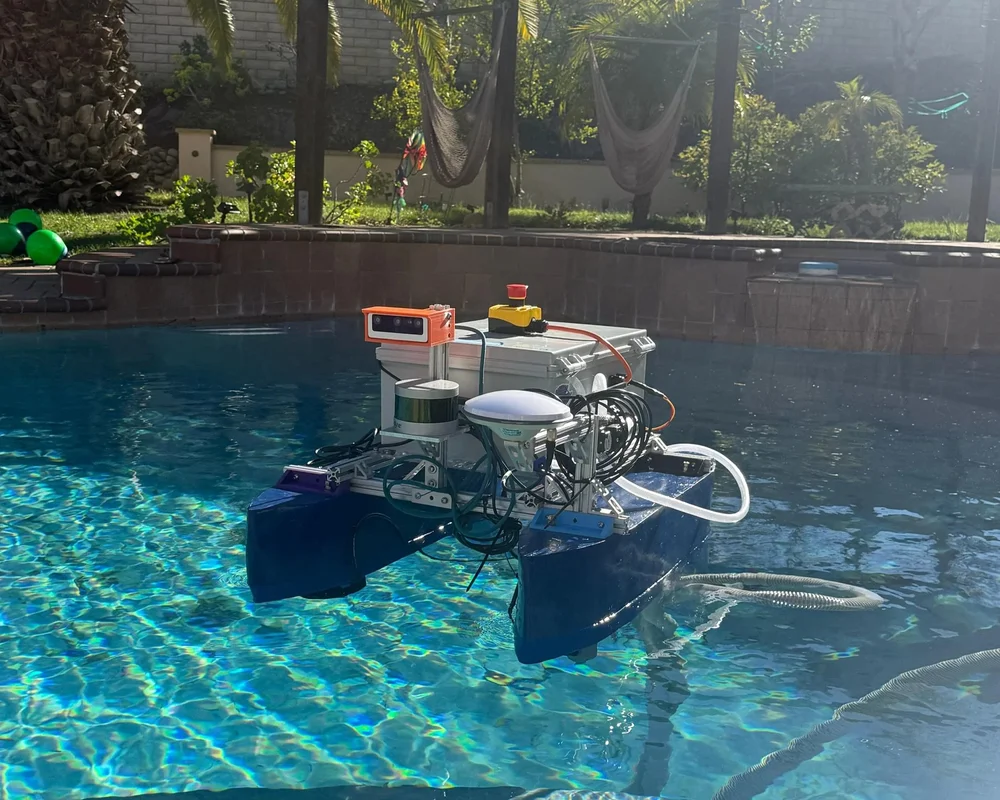
Crusader Proof of Readiness Submission
Weight
24 kg/ 54 lbs
Degrees of Freedom
3 (Surge, Sway, Yaw)
Power System
14.8V, 15.6Ah Li-Ion battery (x1)
Perception Sensors
Oak–D LR camera for stereo vision and object detection (x1)
Mid360 LiDAR (x1)
Wireless Communications
5.8GHz Ubiquiti Bullet AC IP67 (x2)
915 Mhz Telemetry
WiFi
RC 2.4GHz ELRS
Payload
Water Pump
Dimensions
1 m x 0.6 m x 0.4 m
Endurance
Full Throttle – estimated 20 min runtime
Normal Usage – estimated 45 min runtime
Main Processor
Nvidia Jetson Orin Nano
Propulsion System
T200 thrusters (x4) (Holonomic layout)
Navigation System
Centimeter Precision GPS RTK
Dual Dish Antenna GPS
INMP441 MEMS Microphone Module
Software Architecture
Linux-based (Ubuntu 22.04)
Python, ROS 2, Bash