
RobotX 2026
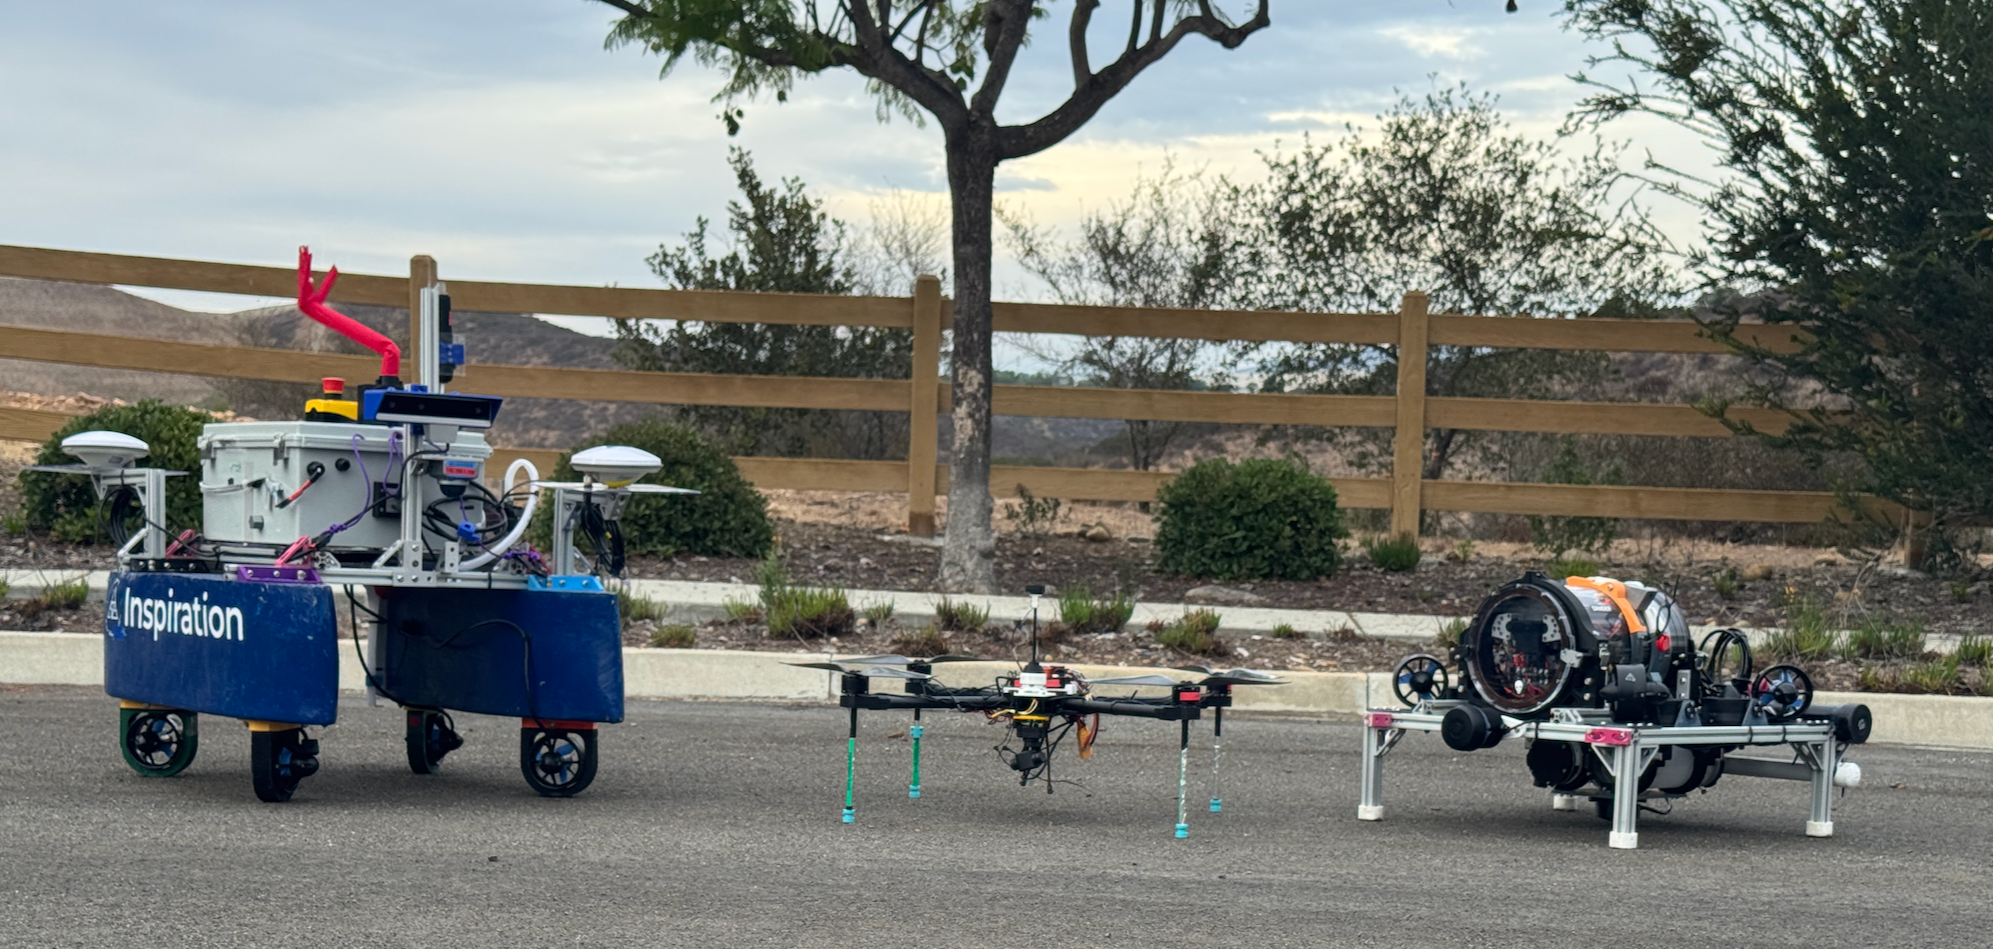
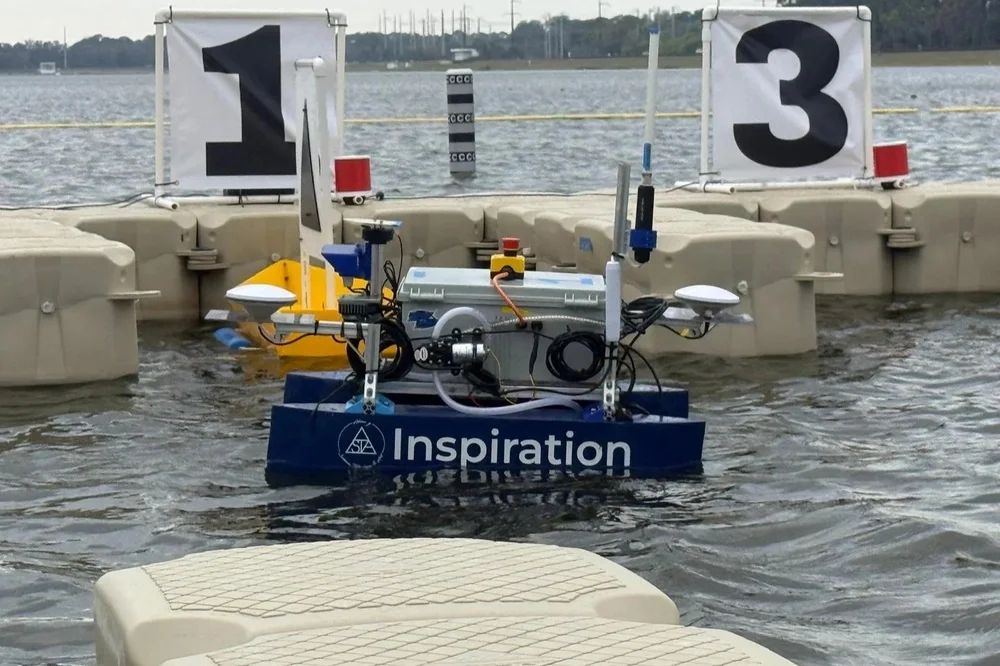
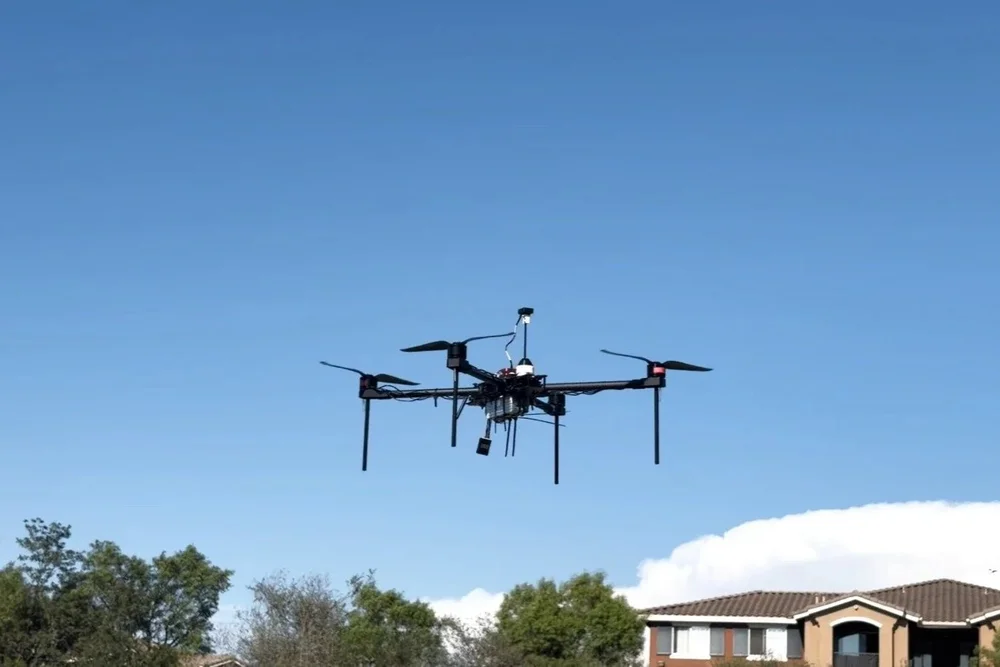
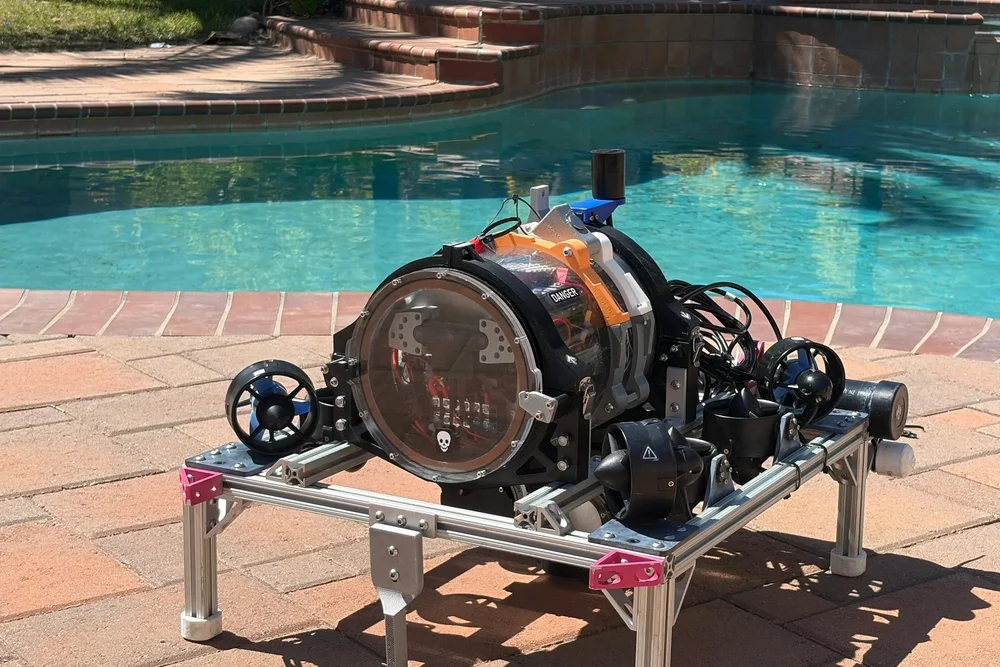
Our 2026 RobotX multi-domain system consists of an Uncrewed Surface Vessel (USV), an Uncrewed Air Vehicle (UAV), and an Uncrewed Underwater Vehicle (UUV). We are the first team to qualify all three vehicles for competition.
In the 2024 RobotX competition, we won 4th Place Overall, 3rd place in Design Documentation, and a special award for Collaborative Systems Engineering.
Vehicles
Crusader - USV
Don/Ekko - UAV
Græy - UUV
Inter Vehicle Communication
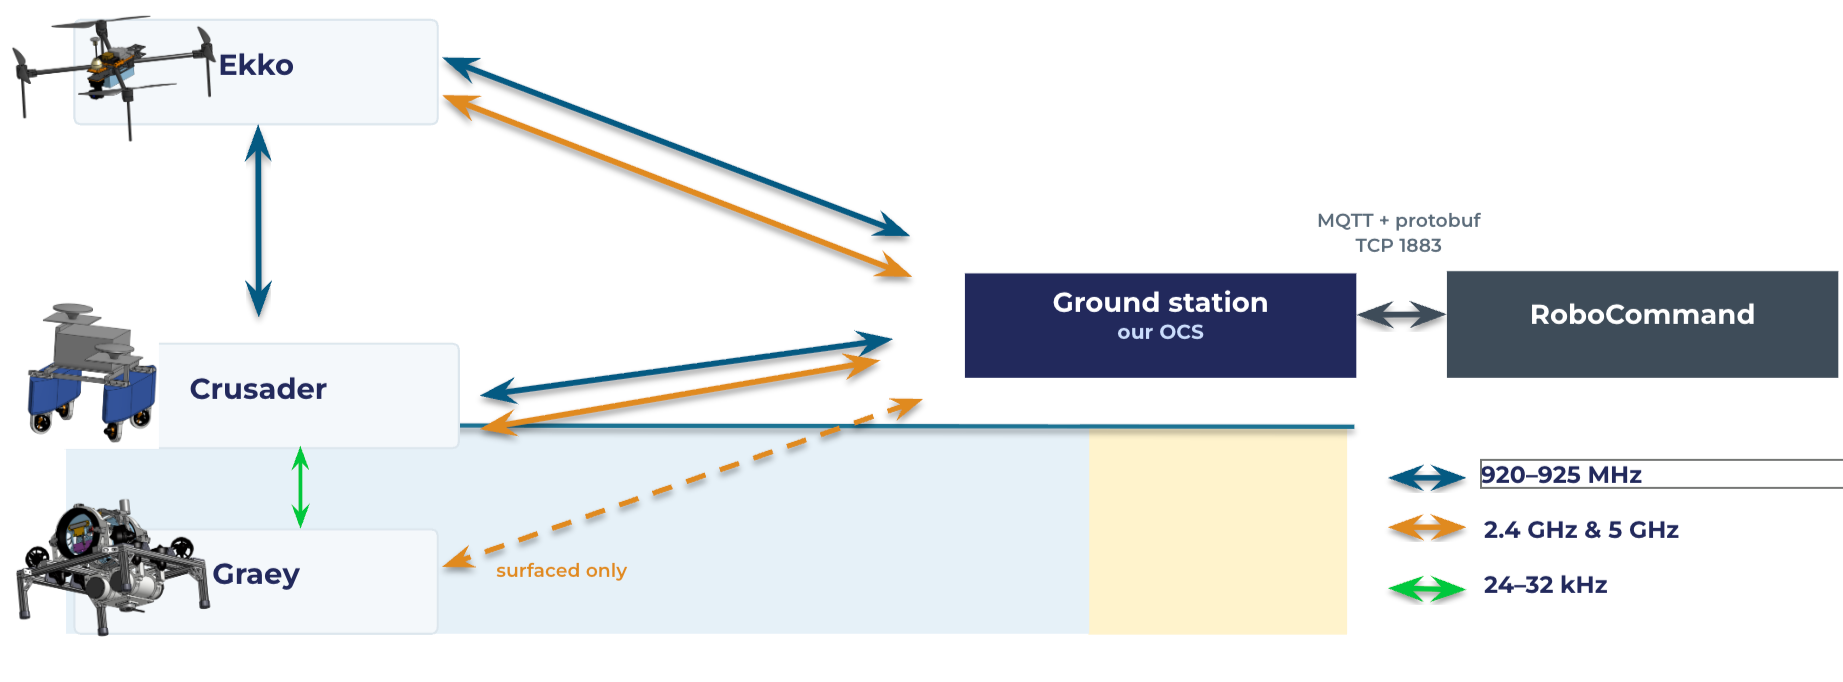
Communication is the foundation of all tasks. We are building a mesh network with multiple links between nodes. When one link is unavailable, a redundant link can be used to transmit information. This redundancy enables superior situational awareness from ground station. Each vehicle can communicate with the ground station through WiFi (which is the 2.4 GHz and 5GHz band), which is mainly used for debugging and transmitting high data rate content like video stream. Our UAV/USV/Ground Station have another 900MHz link that will be used as main source of communication.
Mechanical
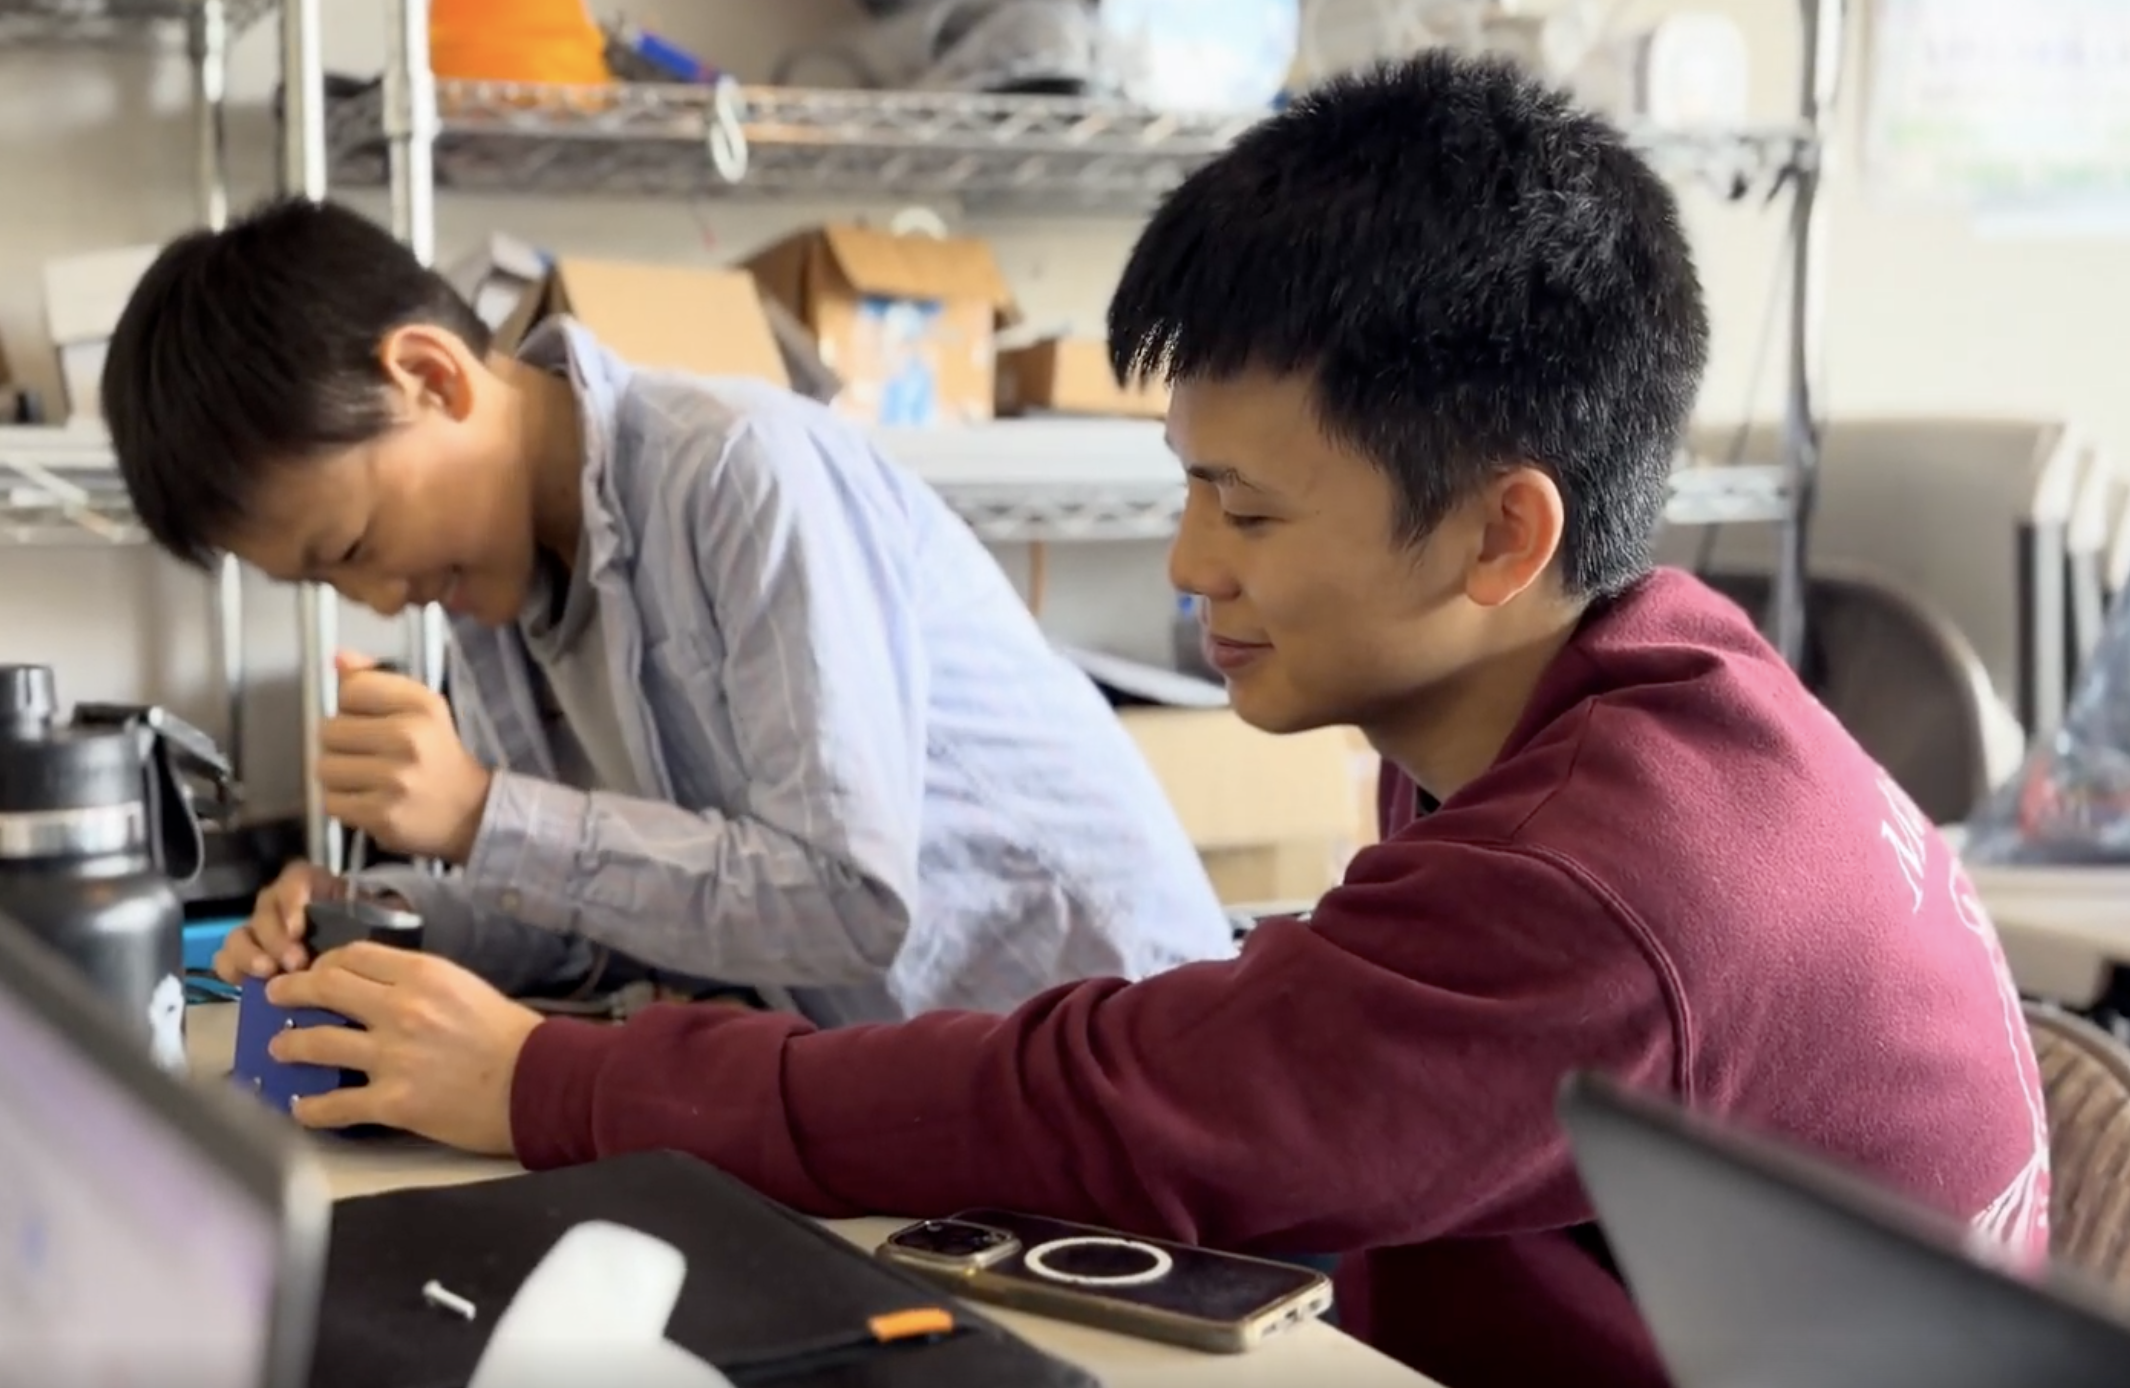
We leverage multiple platforms to unit test different components while also having many vehicles to train up new members. To learn more about the mechanical sub systems per platform click below.
Electrical
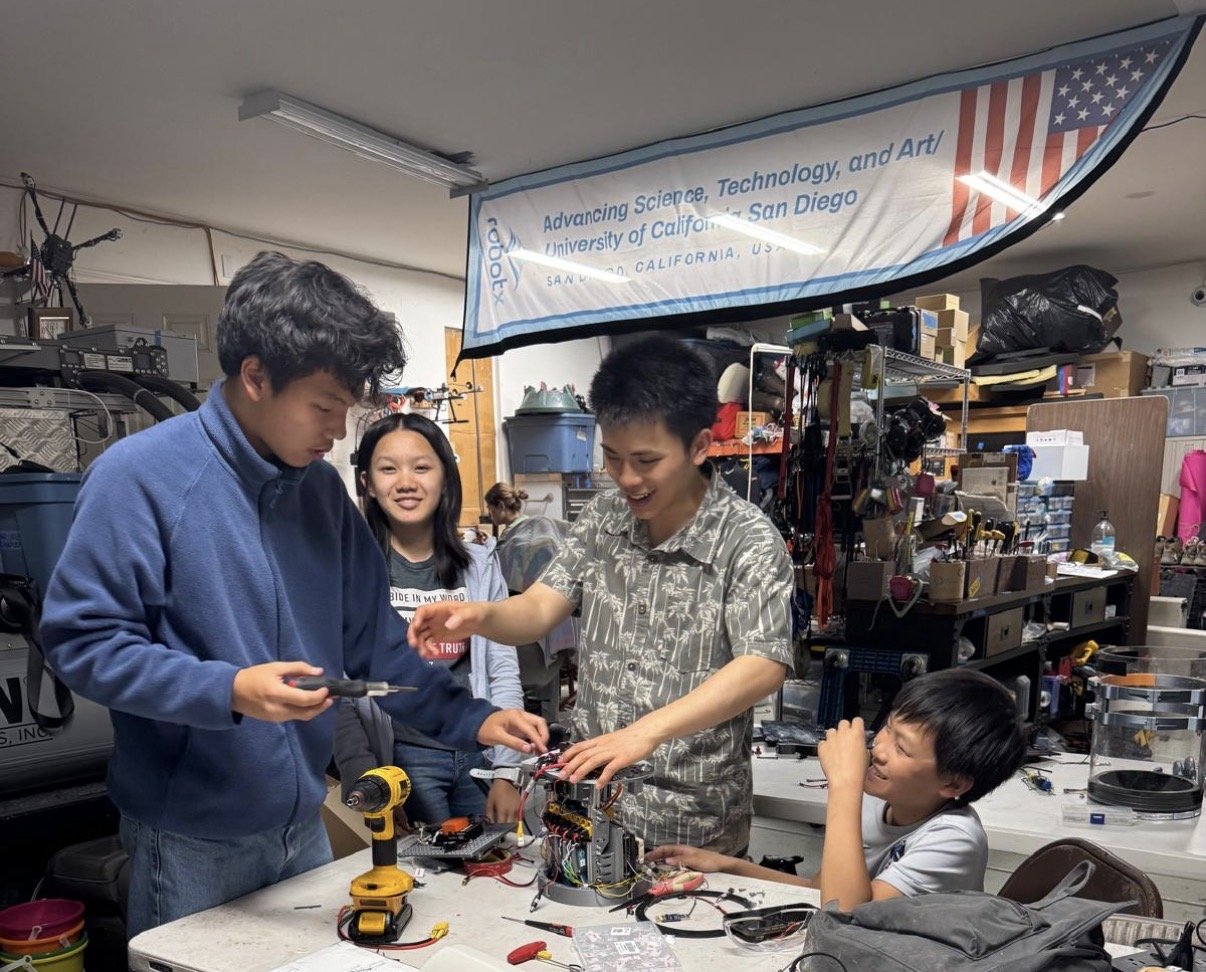
We integrated voltage divider circuits to make a human-machine interface, leveraging LED matrixes to give status of the vehicles for RobotX.
Software
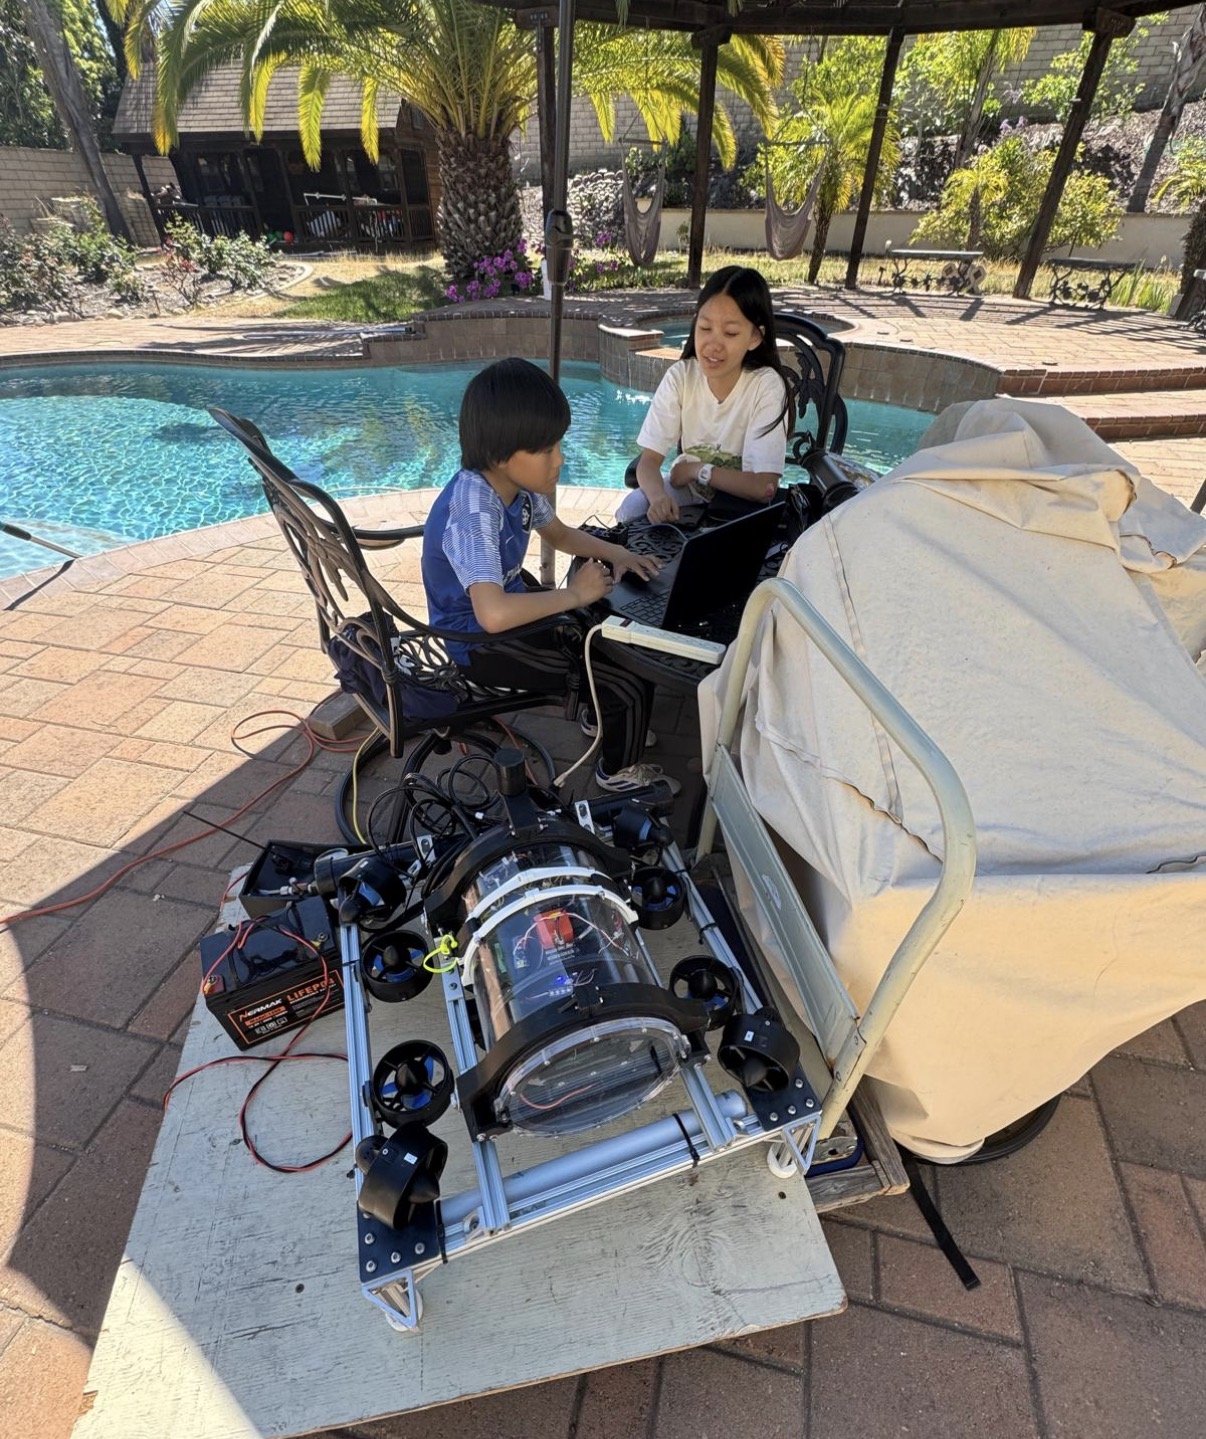
We unified our software architecture across all three platforms by deploying containerized ROS 2 packages through Docker, enabling capabilities developed for one platform to be reused across others with minimal modification. This common architecture accelerates development, maintains consistency across codebases, and simplifies integration.