Crusader (USV), Ekko (UAV), and Graey (UUV) Lake Testing- 10/18/26
Objective
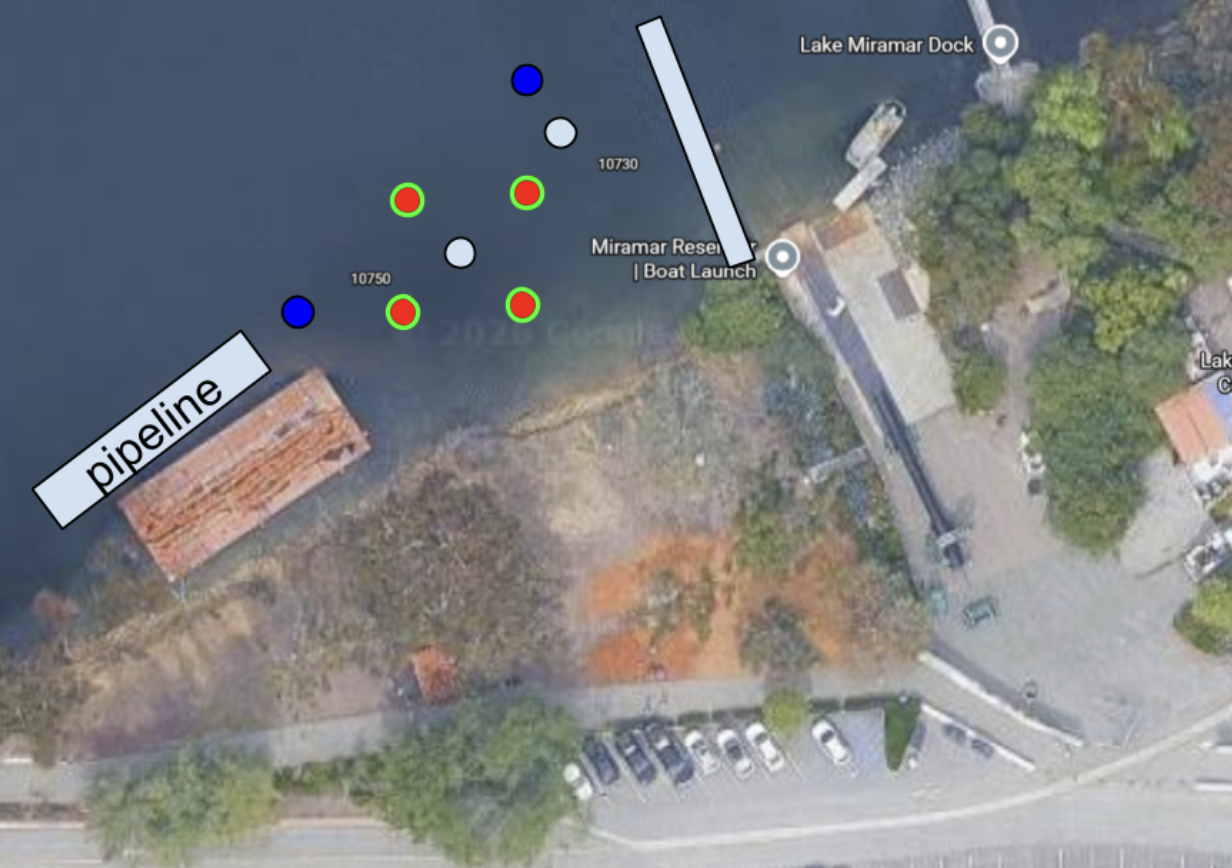
The goal of this test was to see if Crusader, our autonomous boat, could complete Task 1 (disruptive) and work together with our drone, Ekko. To do this, Crusader needed to run its mission using a behavior tree, talk to the drone, and avoid obstacles. We also wanted to collect camera data of the pipeline to help train our computer vision system to detect it.
What Went Well
Buoy setup was faster than last time.
Great weather. It was a beautiful day.
We recorded data.
The drone sent the JSON file successfully.
What worked last time still works now.
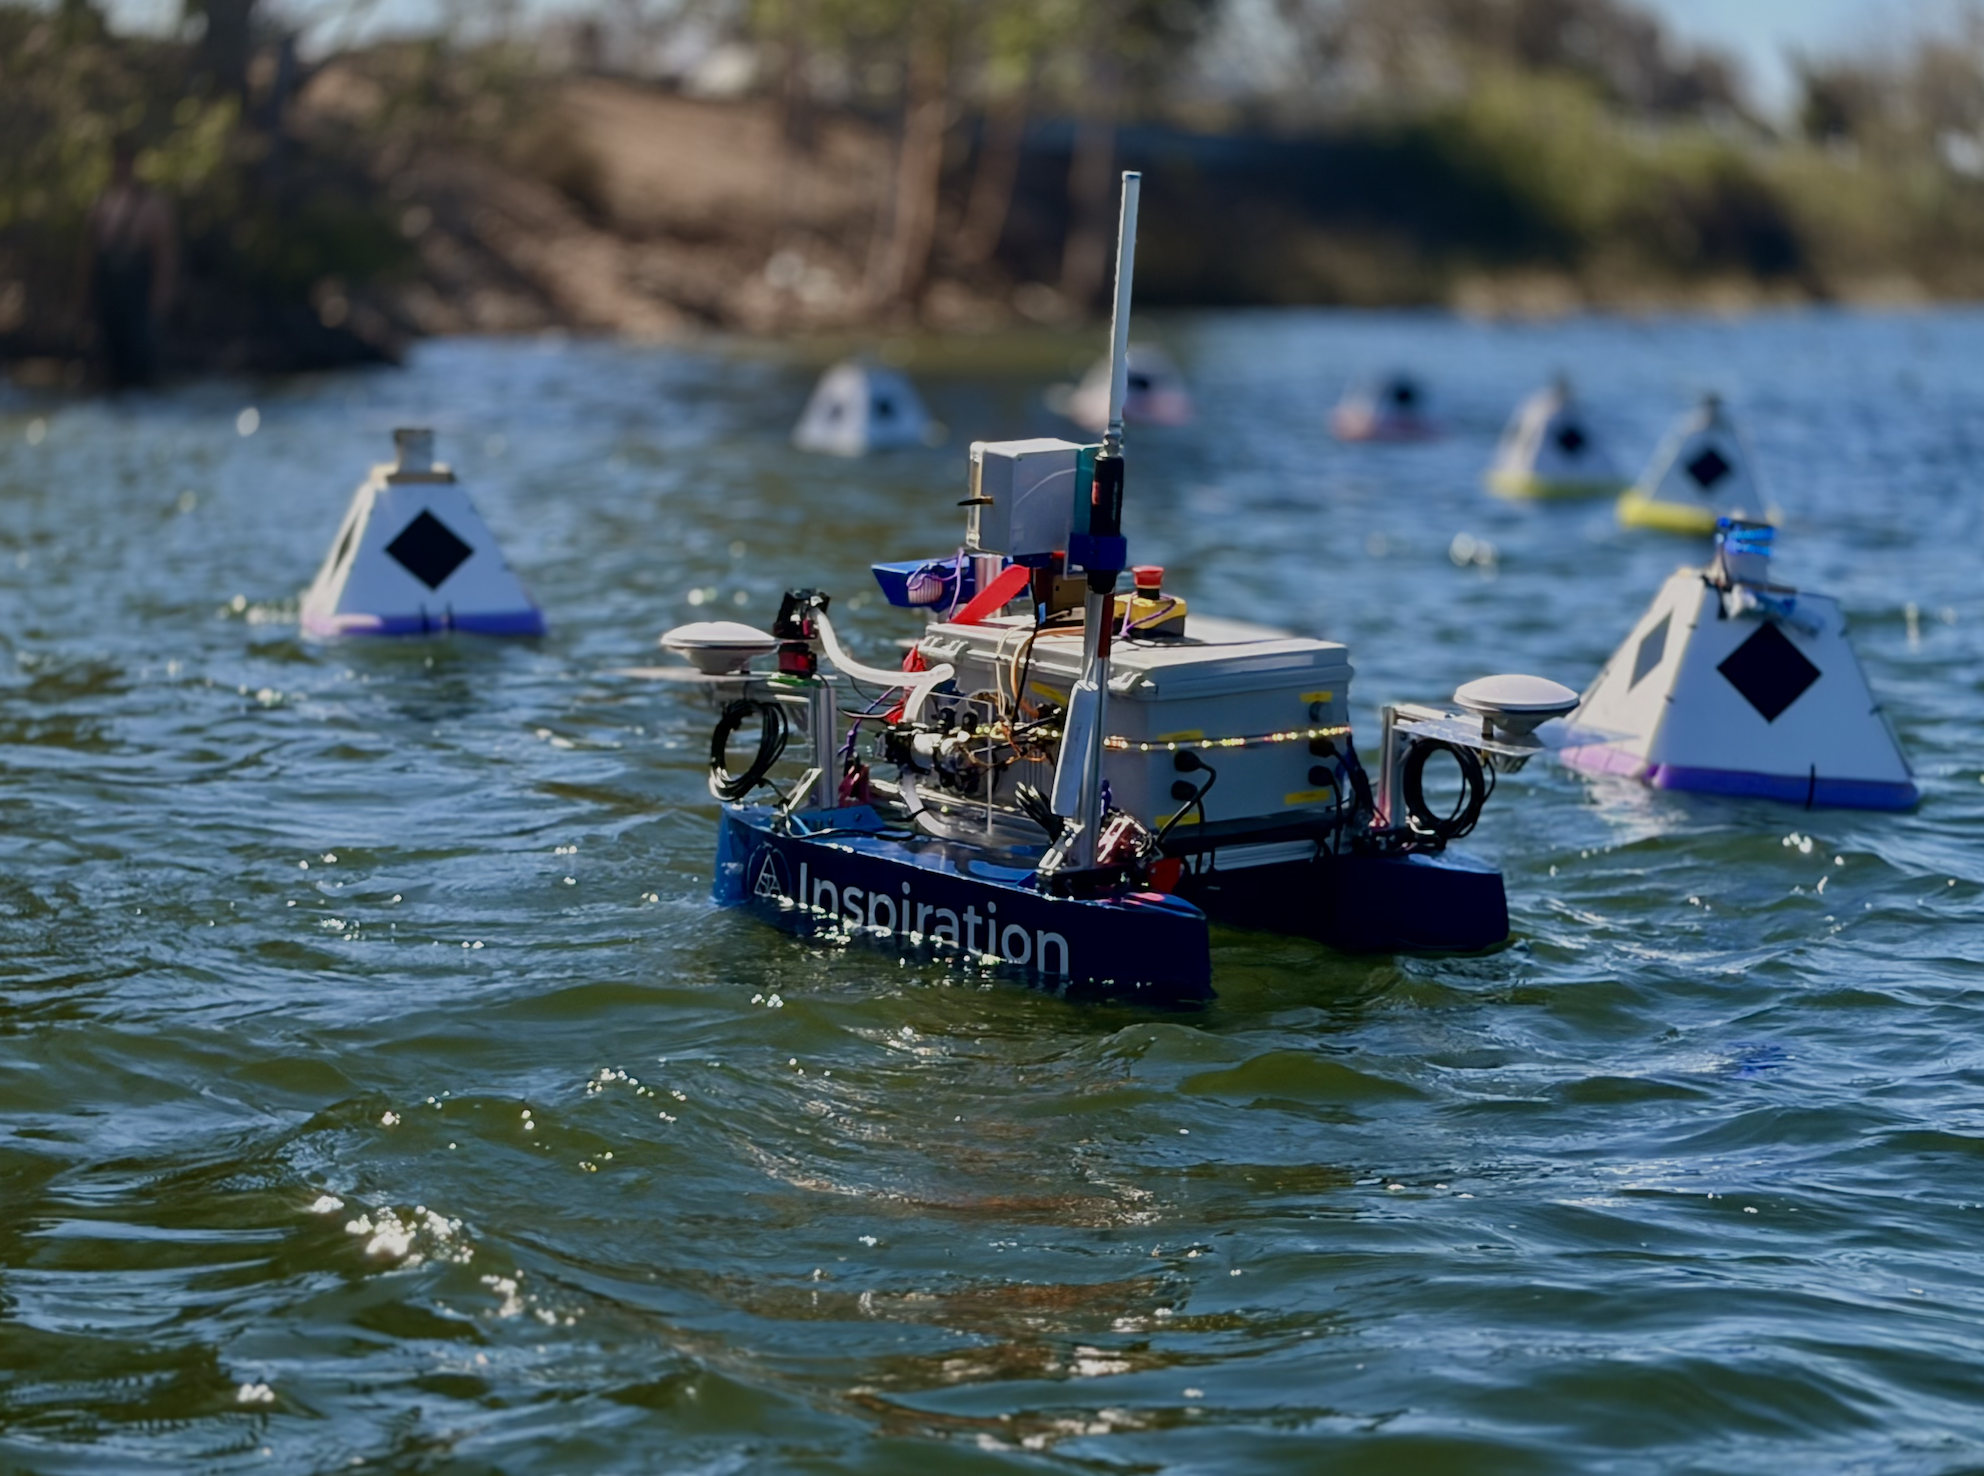
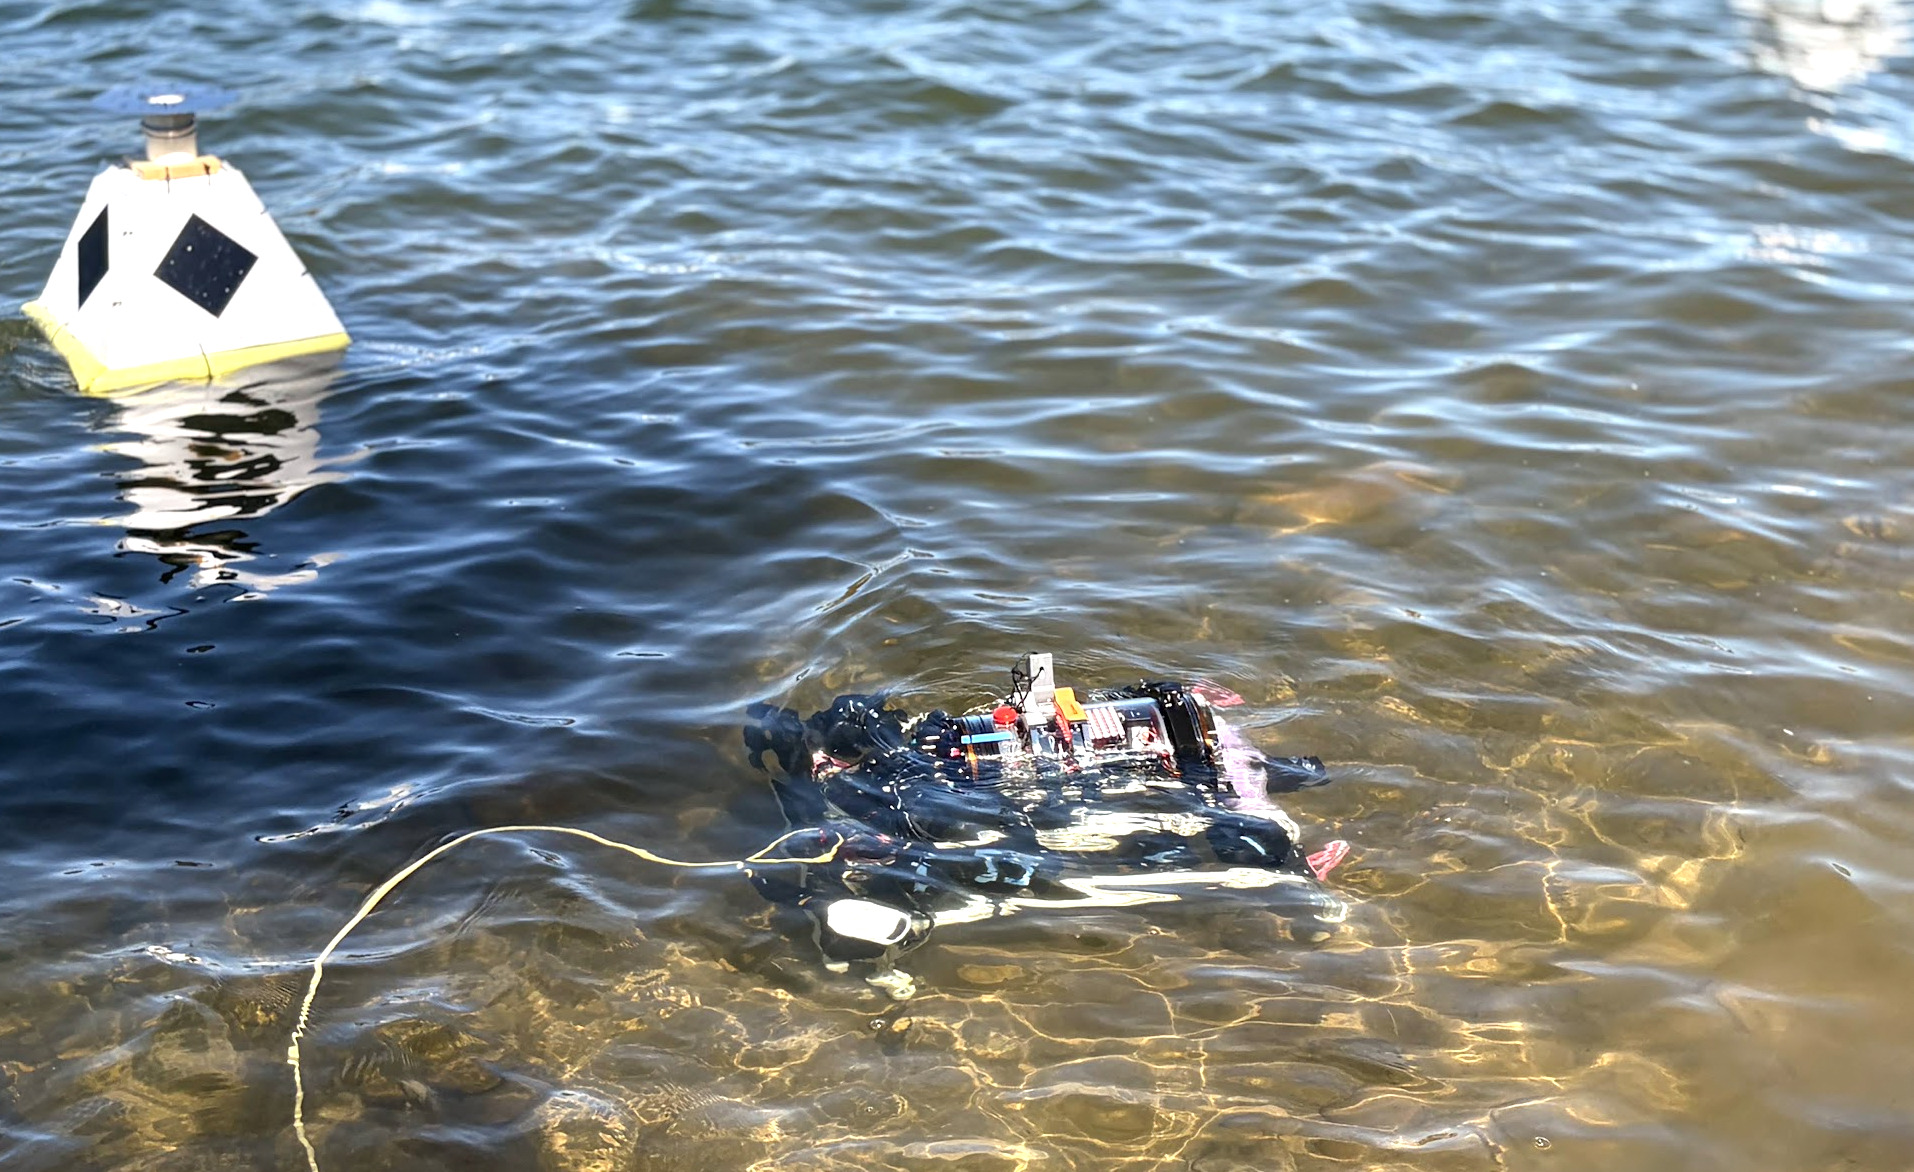
Crusader collecting CV Data
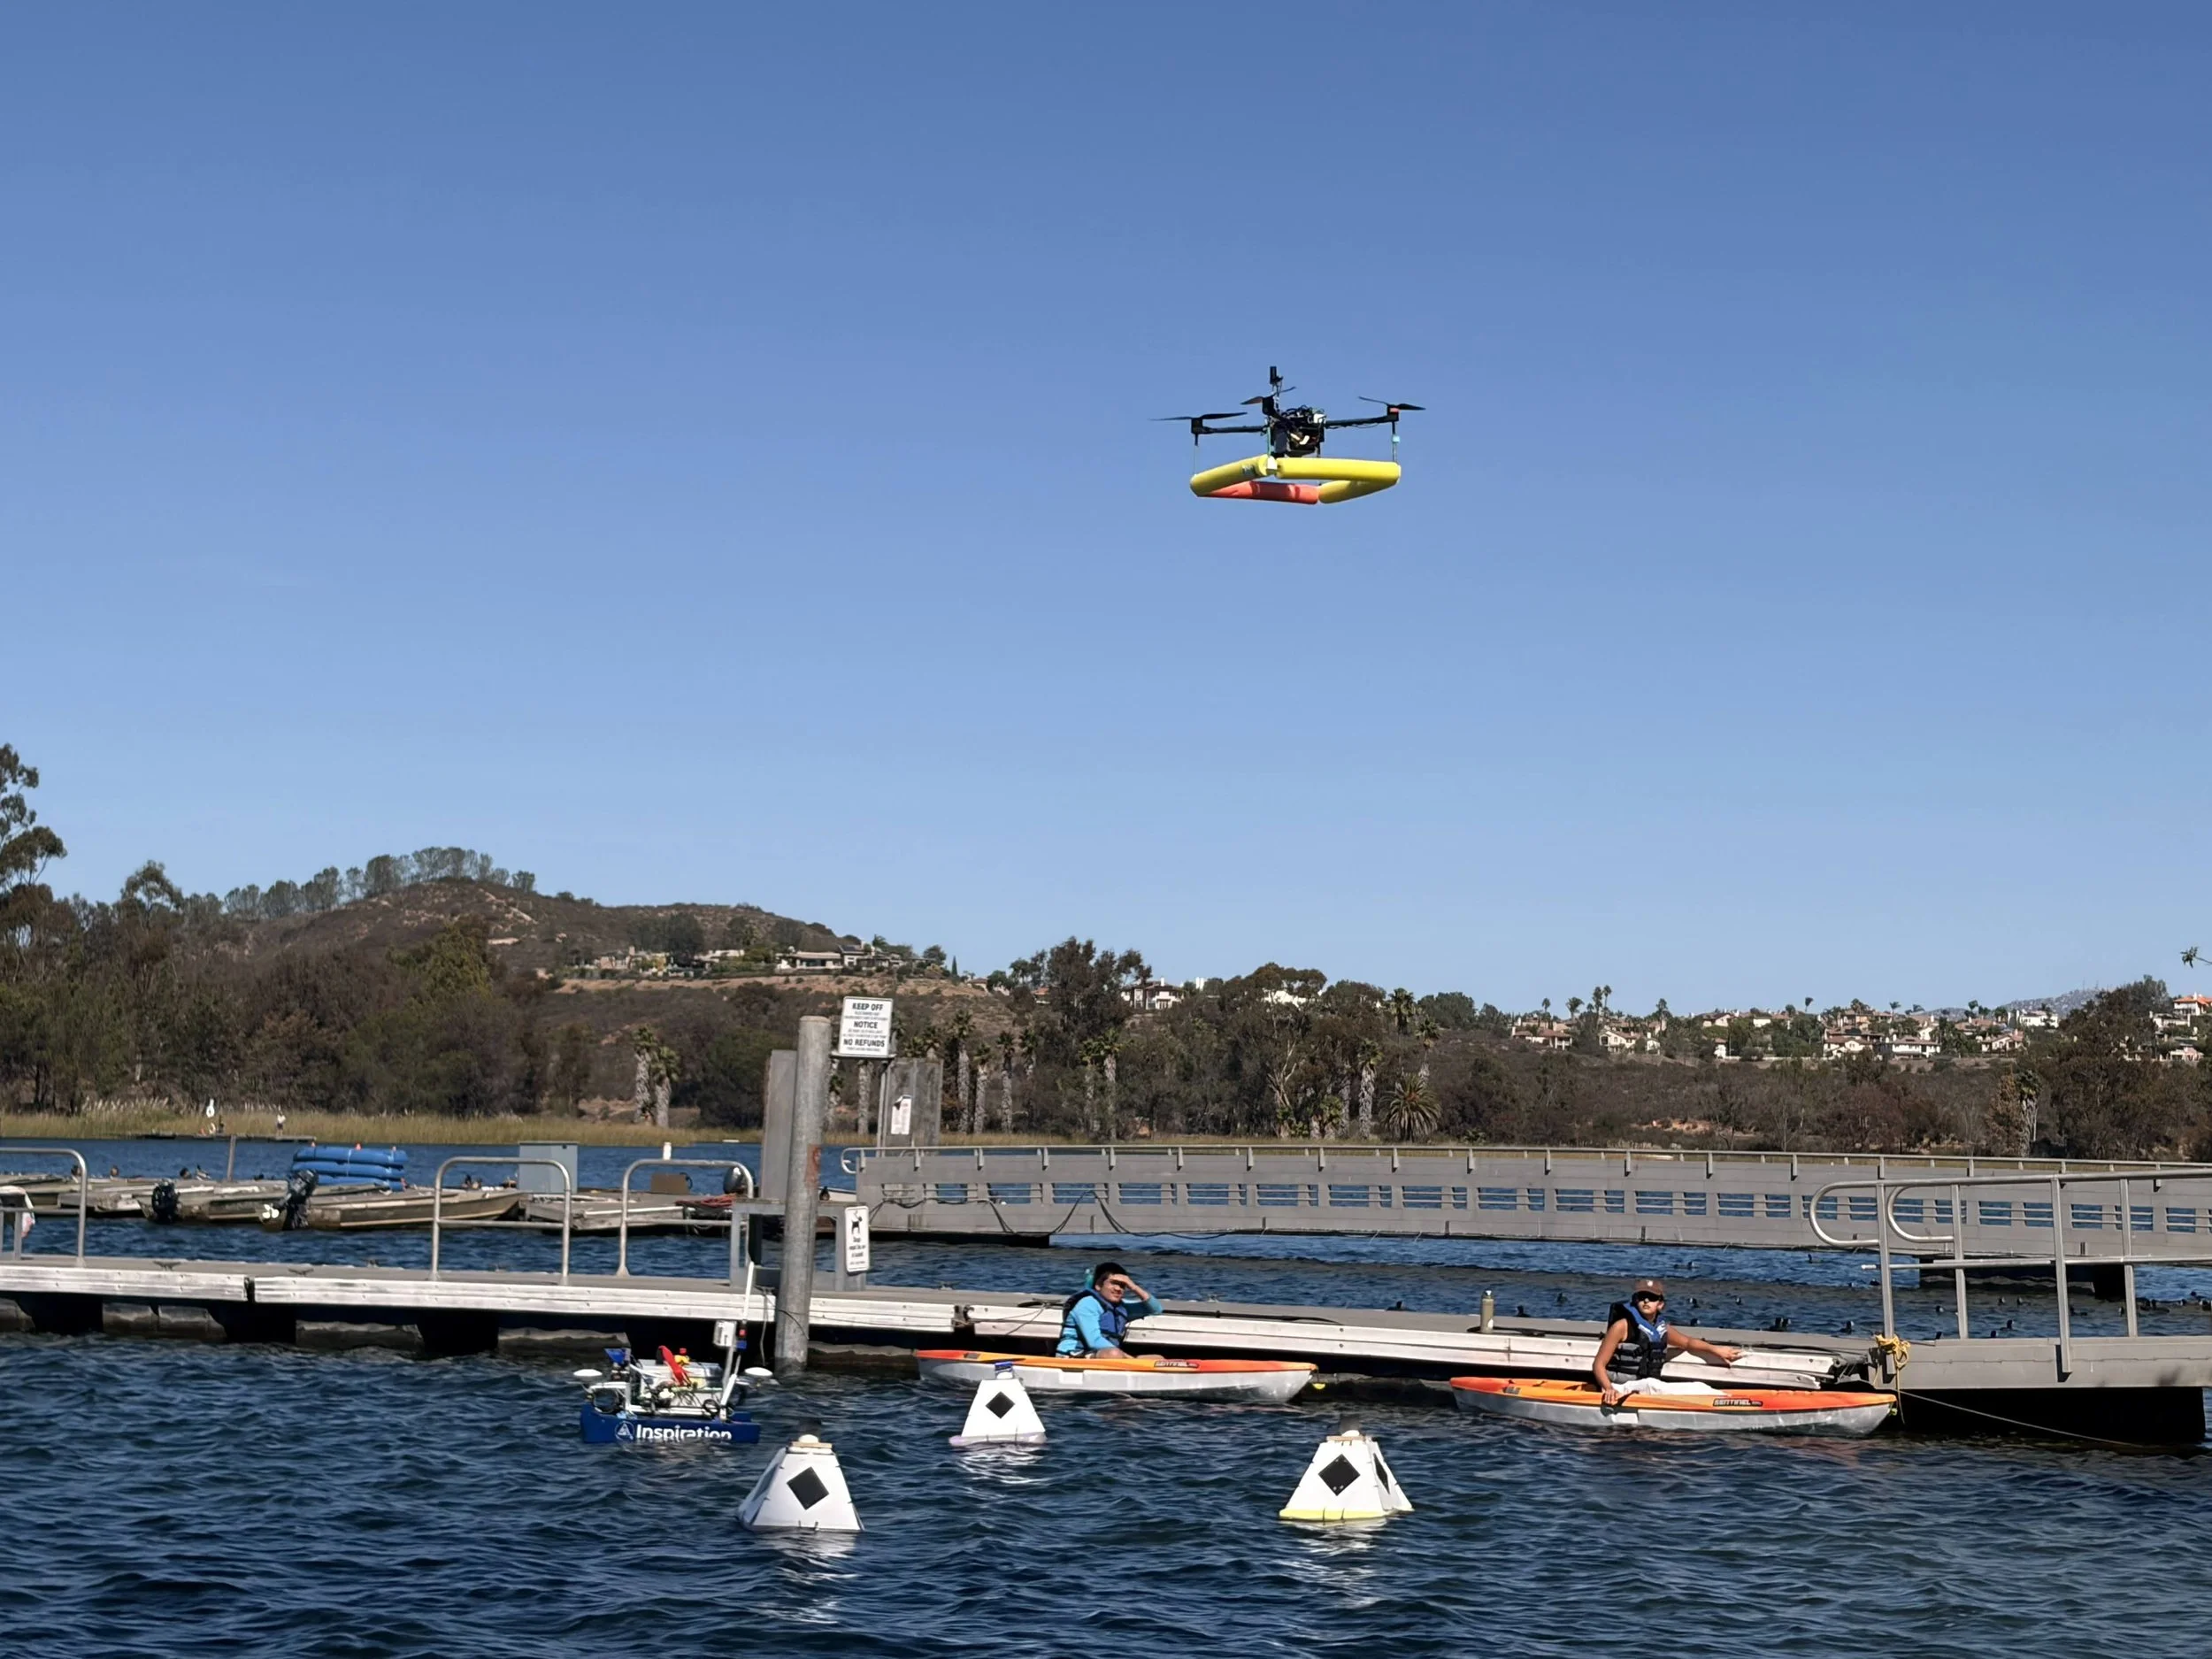
Ekko and Crusader
Problems:
-Buoys
Not enough rope on the buoys, so we were limited in where we could place them.
Buoy deployment could have been better.
The lights on the buoys need to work better for testing.
-Communication
Radio comms between the boat and the drone did not work.
The phone hotspot was not reliable. When it dropped, RTK accuracy fell from 2 cm to about 1 meter.
Walkie-talkies went to the wrong people. The people who had them didn’t need them, and the people who needed them didn’t have them.
-Planning
We did not rehearse the test the day before.
We did not prepare the night before, so our testing schedule was delayed.
Next Time
Prepare and rehearse the night before.
Bring more supplies: weights, string, rope, and walkie-talkies.
Give walkie-talkies to the people who need them, like the boat crew and buoy team.
Lock down task assignments and don’t change them on test day.
Focus on precision, not speed, when placing buoys.
Use the shallow area to place buoys by hand while wearing coveralls.
Add more ways to lock down the pipeline.
Hang the pipeline in deeper water, away from both the surface and the lake floor.
Find a better internet connection than a phone hotspot so RTK stays accurate.
Fix the boat-to-drone radio link before the next test.
Here is the link to more photos/videos: https://photos.app.goo.gl/z6iWtCANtD2gkSoo8