Objective:
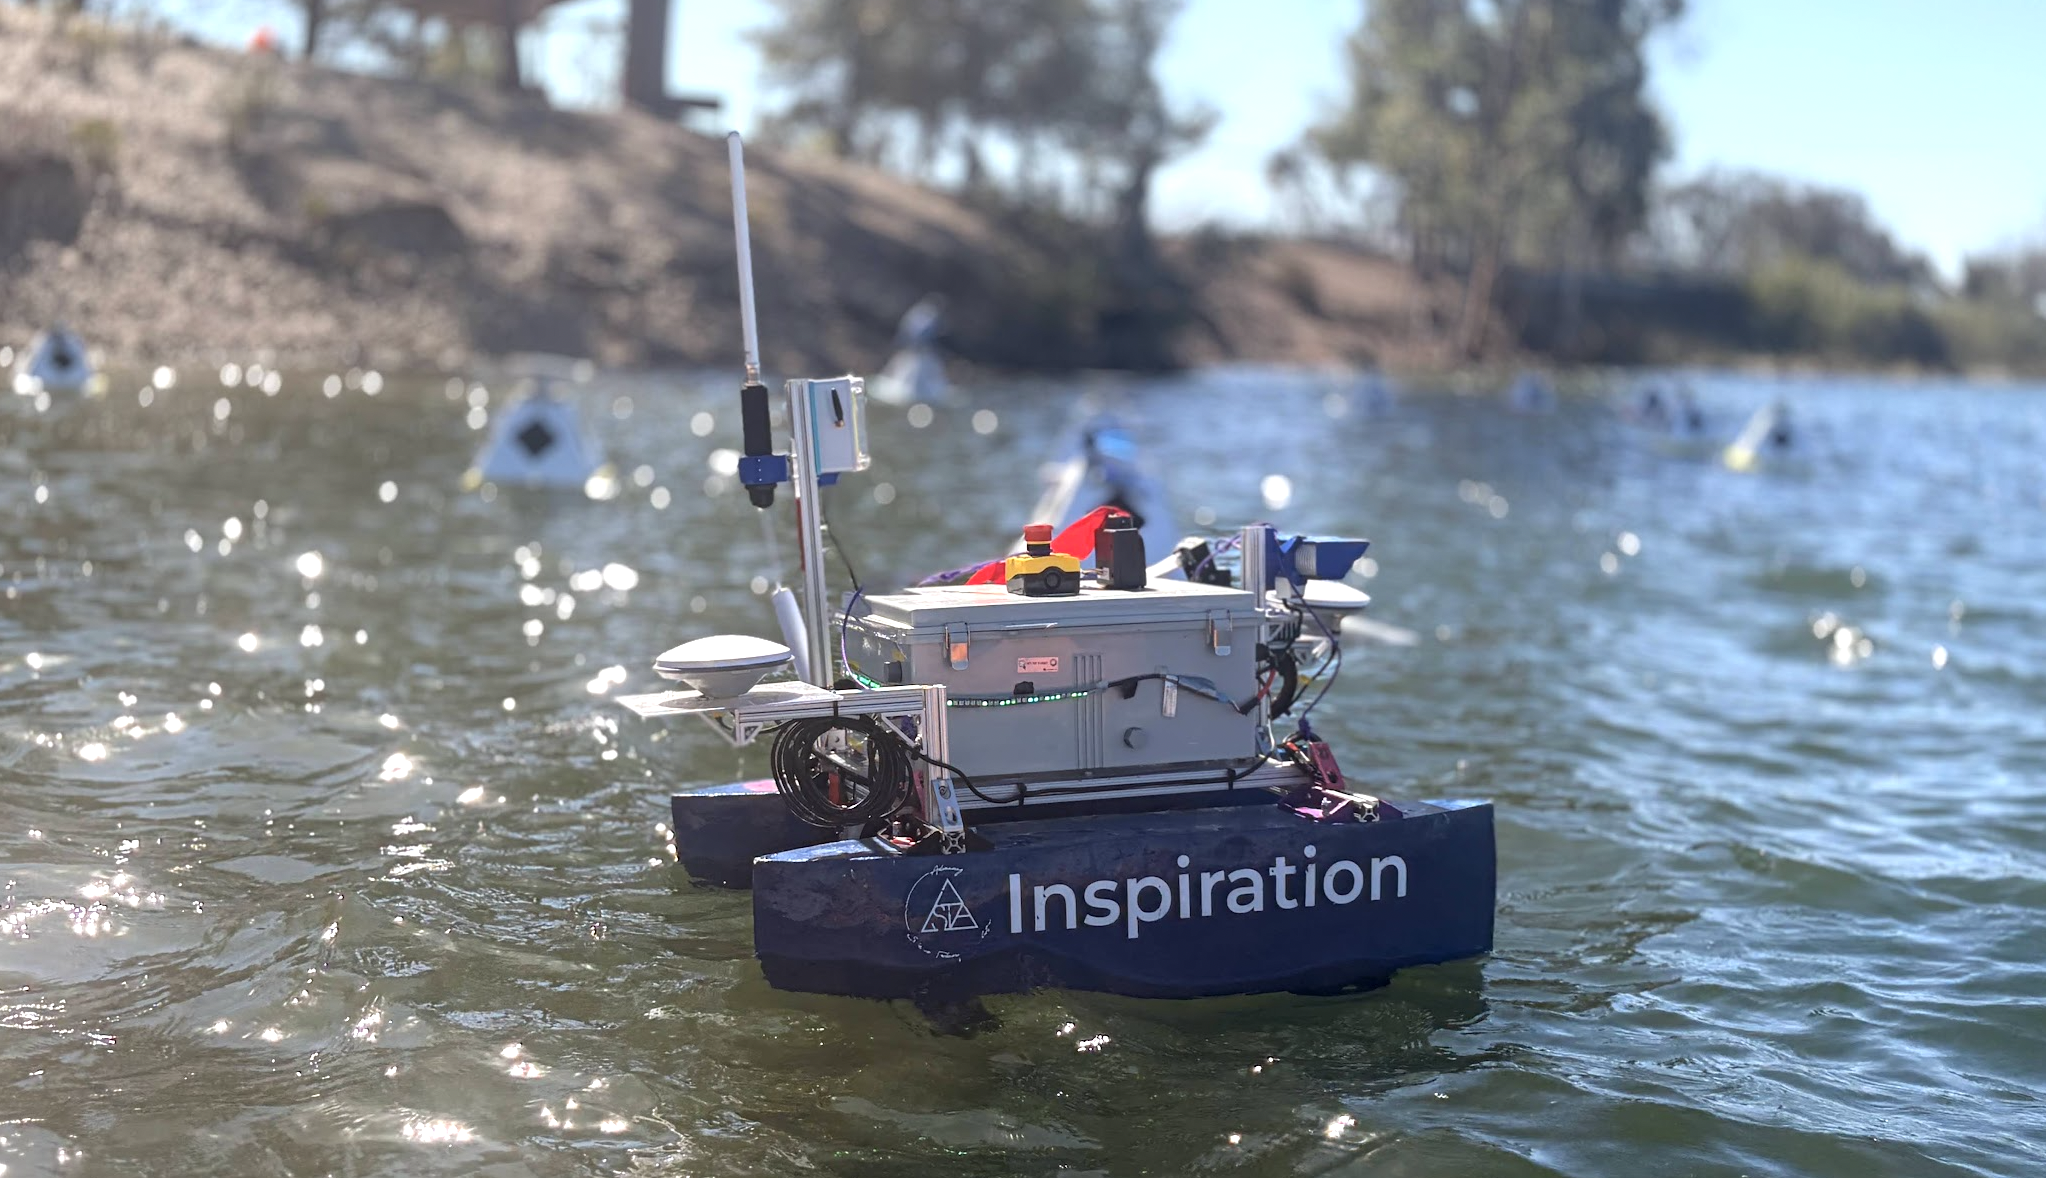
The goal of this test was to try all of our vehicles at the lake. The main goal was Task 1 Advanced. The drone would fly over the buoy field, map it, and send the map to the boat. Then the boat would drive through the buoy field without hitting any buoys, ideally in under 2.5 minutes. Our other goals were to test Task 2 and Task 3, test the sub’s GPS heading and navigation on the surface and underwater, and test Robocommand reporting.
Timeline
12:00 – Planned time to leave
14:25 – Boat battery at 15.5 V. We only had one RTK account, so only the drone used RTK.
Task 3 attempt – The water shooter was too weak to reach the upper window. The boat held its heading well, but the heading reset when we restarted the mission. We fixed this on the spot.
15:00 – Boat kept working on Task 3.d
15:27 – Boat battery dropped to 14.4 V. Swapped to a 16.2 V battery (4.05 V per cell).
15:38 – Task 1 Advanced with drone and boat was a success. It took 6 minutes because the boat was too slow on pool settings. We switched to faster settings (WP_SPEED = 1.2, WP_RADIUS = 1.2).
16:06 – The boat hit the shore and broke its thruster guard.
16:10 – Tested the drone’s auto search program.
What Went Well
The drone sent the buoy field map to the boat well.
Drone-to-boat communication was solid.
The boat followed its path well after switching to lake settings.
The flapper worked.
The buoys worked, and none sank.
We did not like how the search program mapped the starting spot, so we made a new search area inside the geofence on the spot.
The wind was very strong, but we handled it.
What Could Be Better
Bring a spare motor mount.
Untangle the rope before giving it to the kayaker.
Get a bigger regulator for the Task 3 LED board.
Bring one more team member next time.
Do not cut the anchor rope. Tie off the extra rope and keep it.
The short buoy drifted.
Make sure all batteries are charged.
Communicate better about which batteries are charged and which are not.
Use the checklist. We forgot the paddles and life vests.
Bring the drone launch platform.
Share the boat transmitter so someone else can take over if the boat is in danger.
Next Steps
Set up drone-to-sub communication.
Start printing spare parts for the vehicles.