
Robot X- Sub Electrical
RobotX 2026 > Sub Electrical
Graey utilizes a Jetsons Nano as onboard computers. To enable autonomous movement, Graey uses a Pixhawk 4 as flight controllers. The external sensors communicate with systems in the main electronics enclosure via connectors that are sealed from the inside and the outside of the main end cap, rather than simple penetrators that can fail with weak epoxy.
Overview
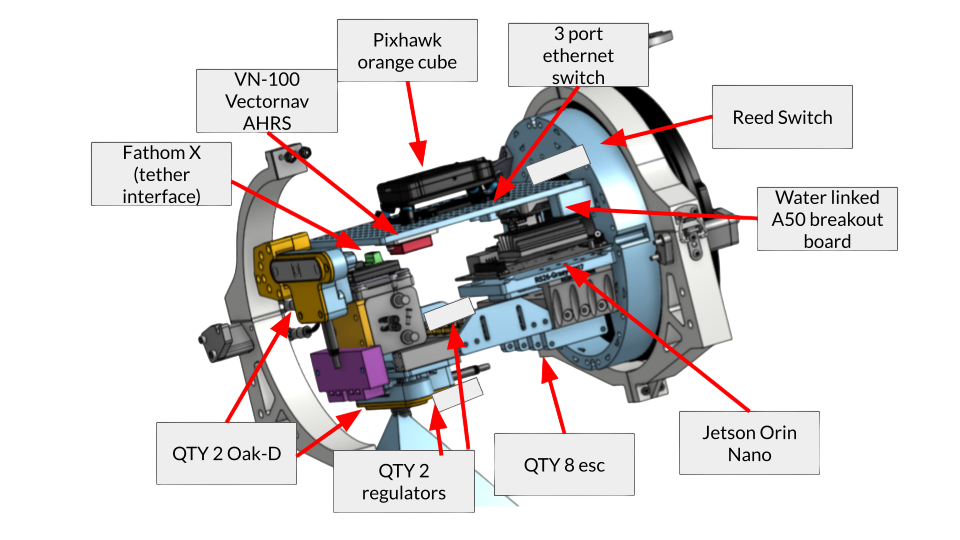
We’ve revamped Graey’s electrical system by fully constraining the system since before, everything was on slides so anytime we needed to adjust something inside the camera would shift positions. Now, Graey’s electrical system is more simple, and fully constratined.
System Diagrams
Standardized Kill Switch System
The team pivoted away from the previous kill switch system to enable longer endurance. The implemented design isolates our noisy ESC line from our sensitive payload and sensor line. We built off competition success inspired by the team’s 2024 RoboBoat kill switch system, implementing IRhapsody relay with a ground trigger. Instead of an external red button, utilized in RoboBoat, we utilize a reed switch to detect a magnetic latch accessible by the divers external to the payload enclosure.
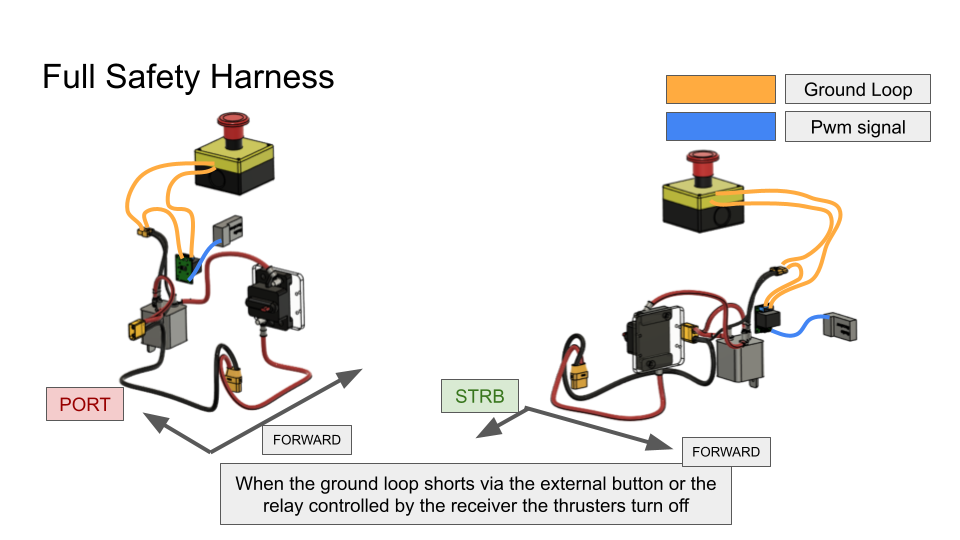
RoboBoat Safety harness with remote and onboard trigger systems
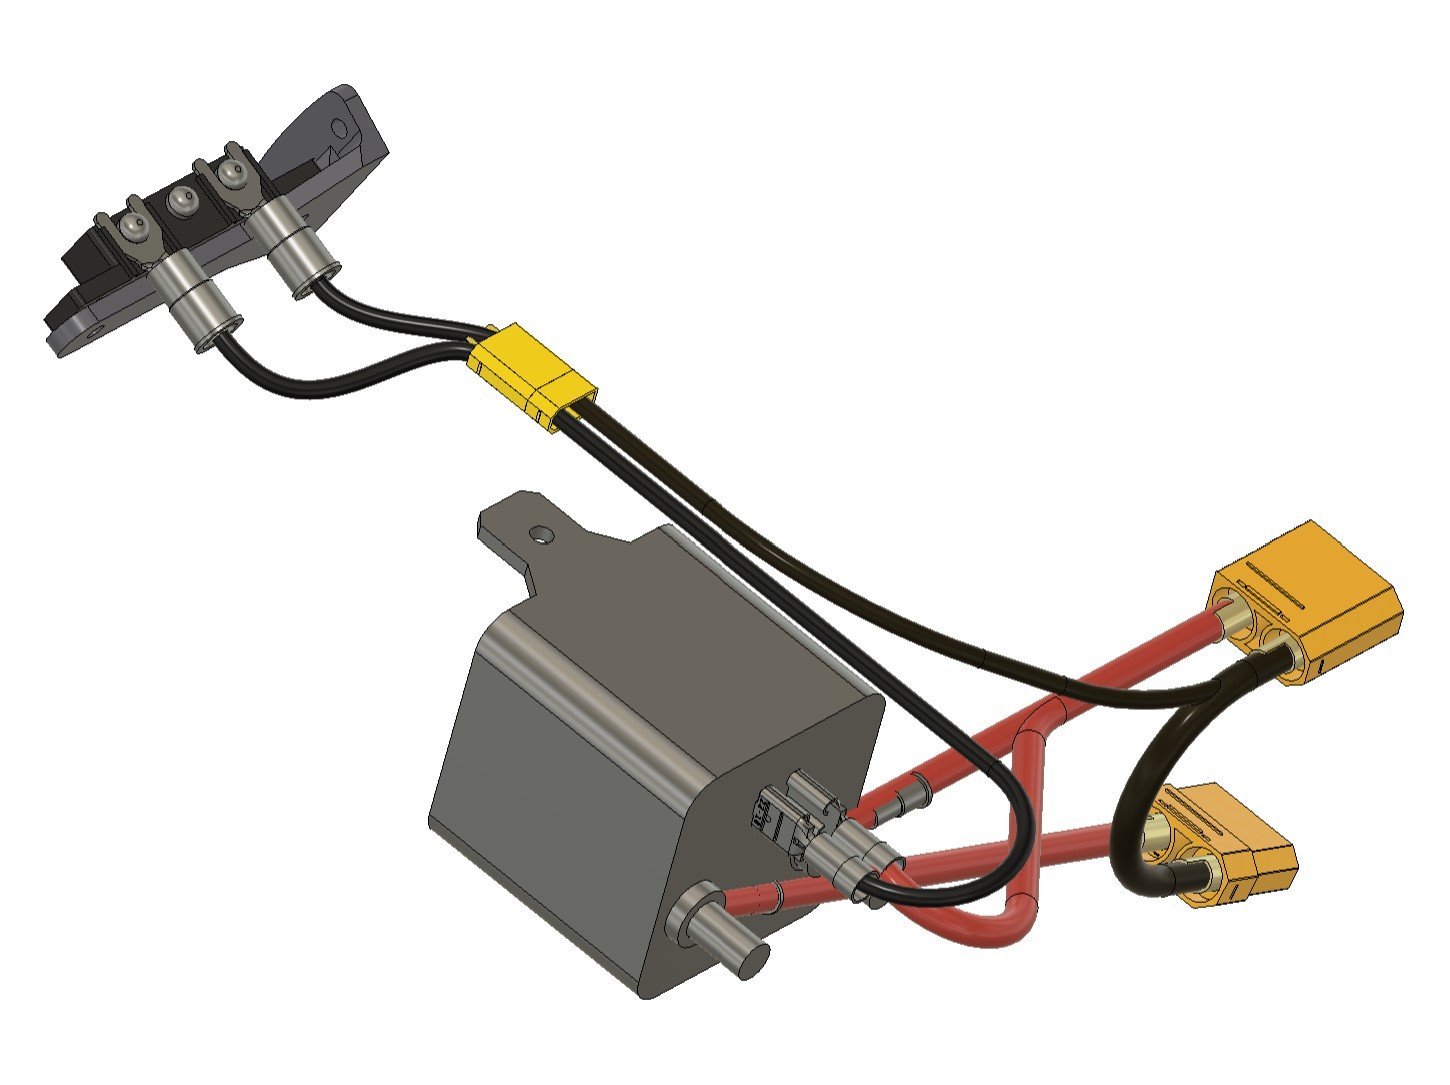
Safety harness with reed switch for Graey
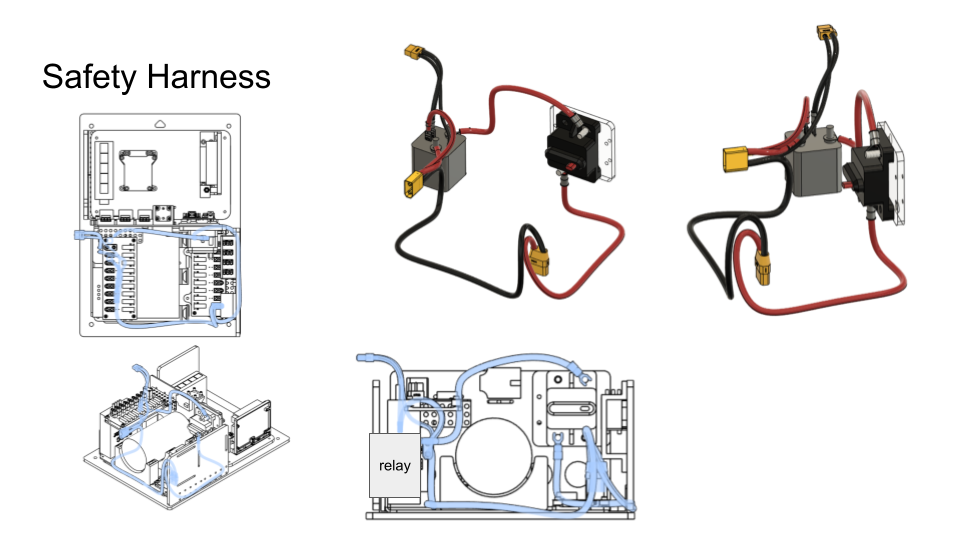
RoboBoat Safety harness in context with the fuse board and regulators
Custom Fuse PCB
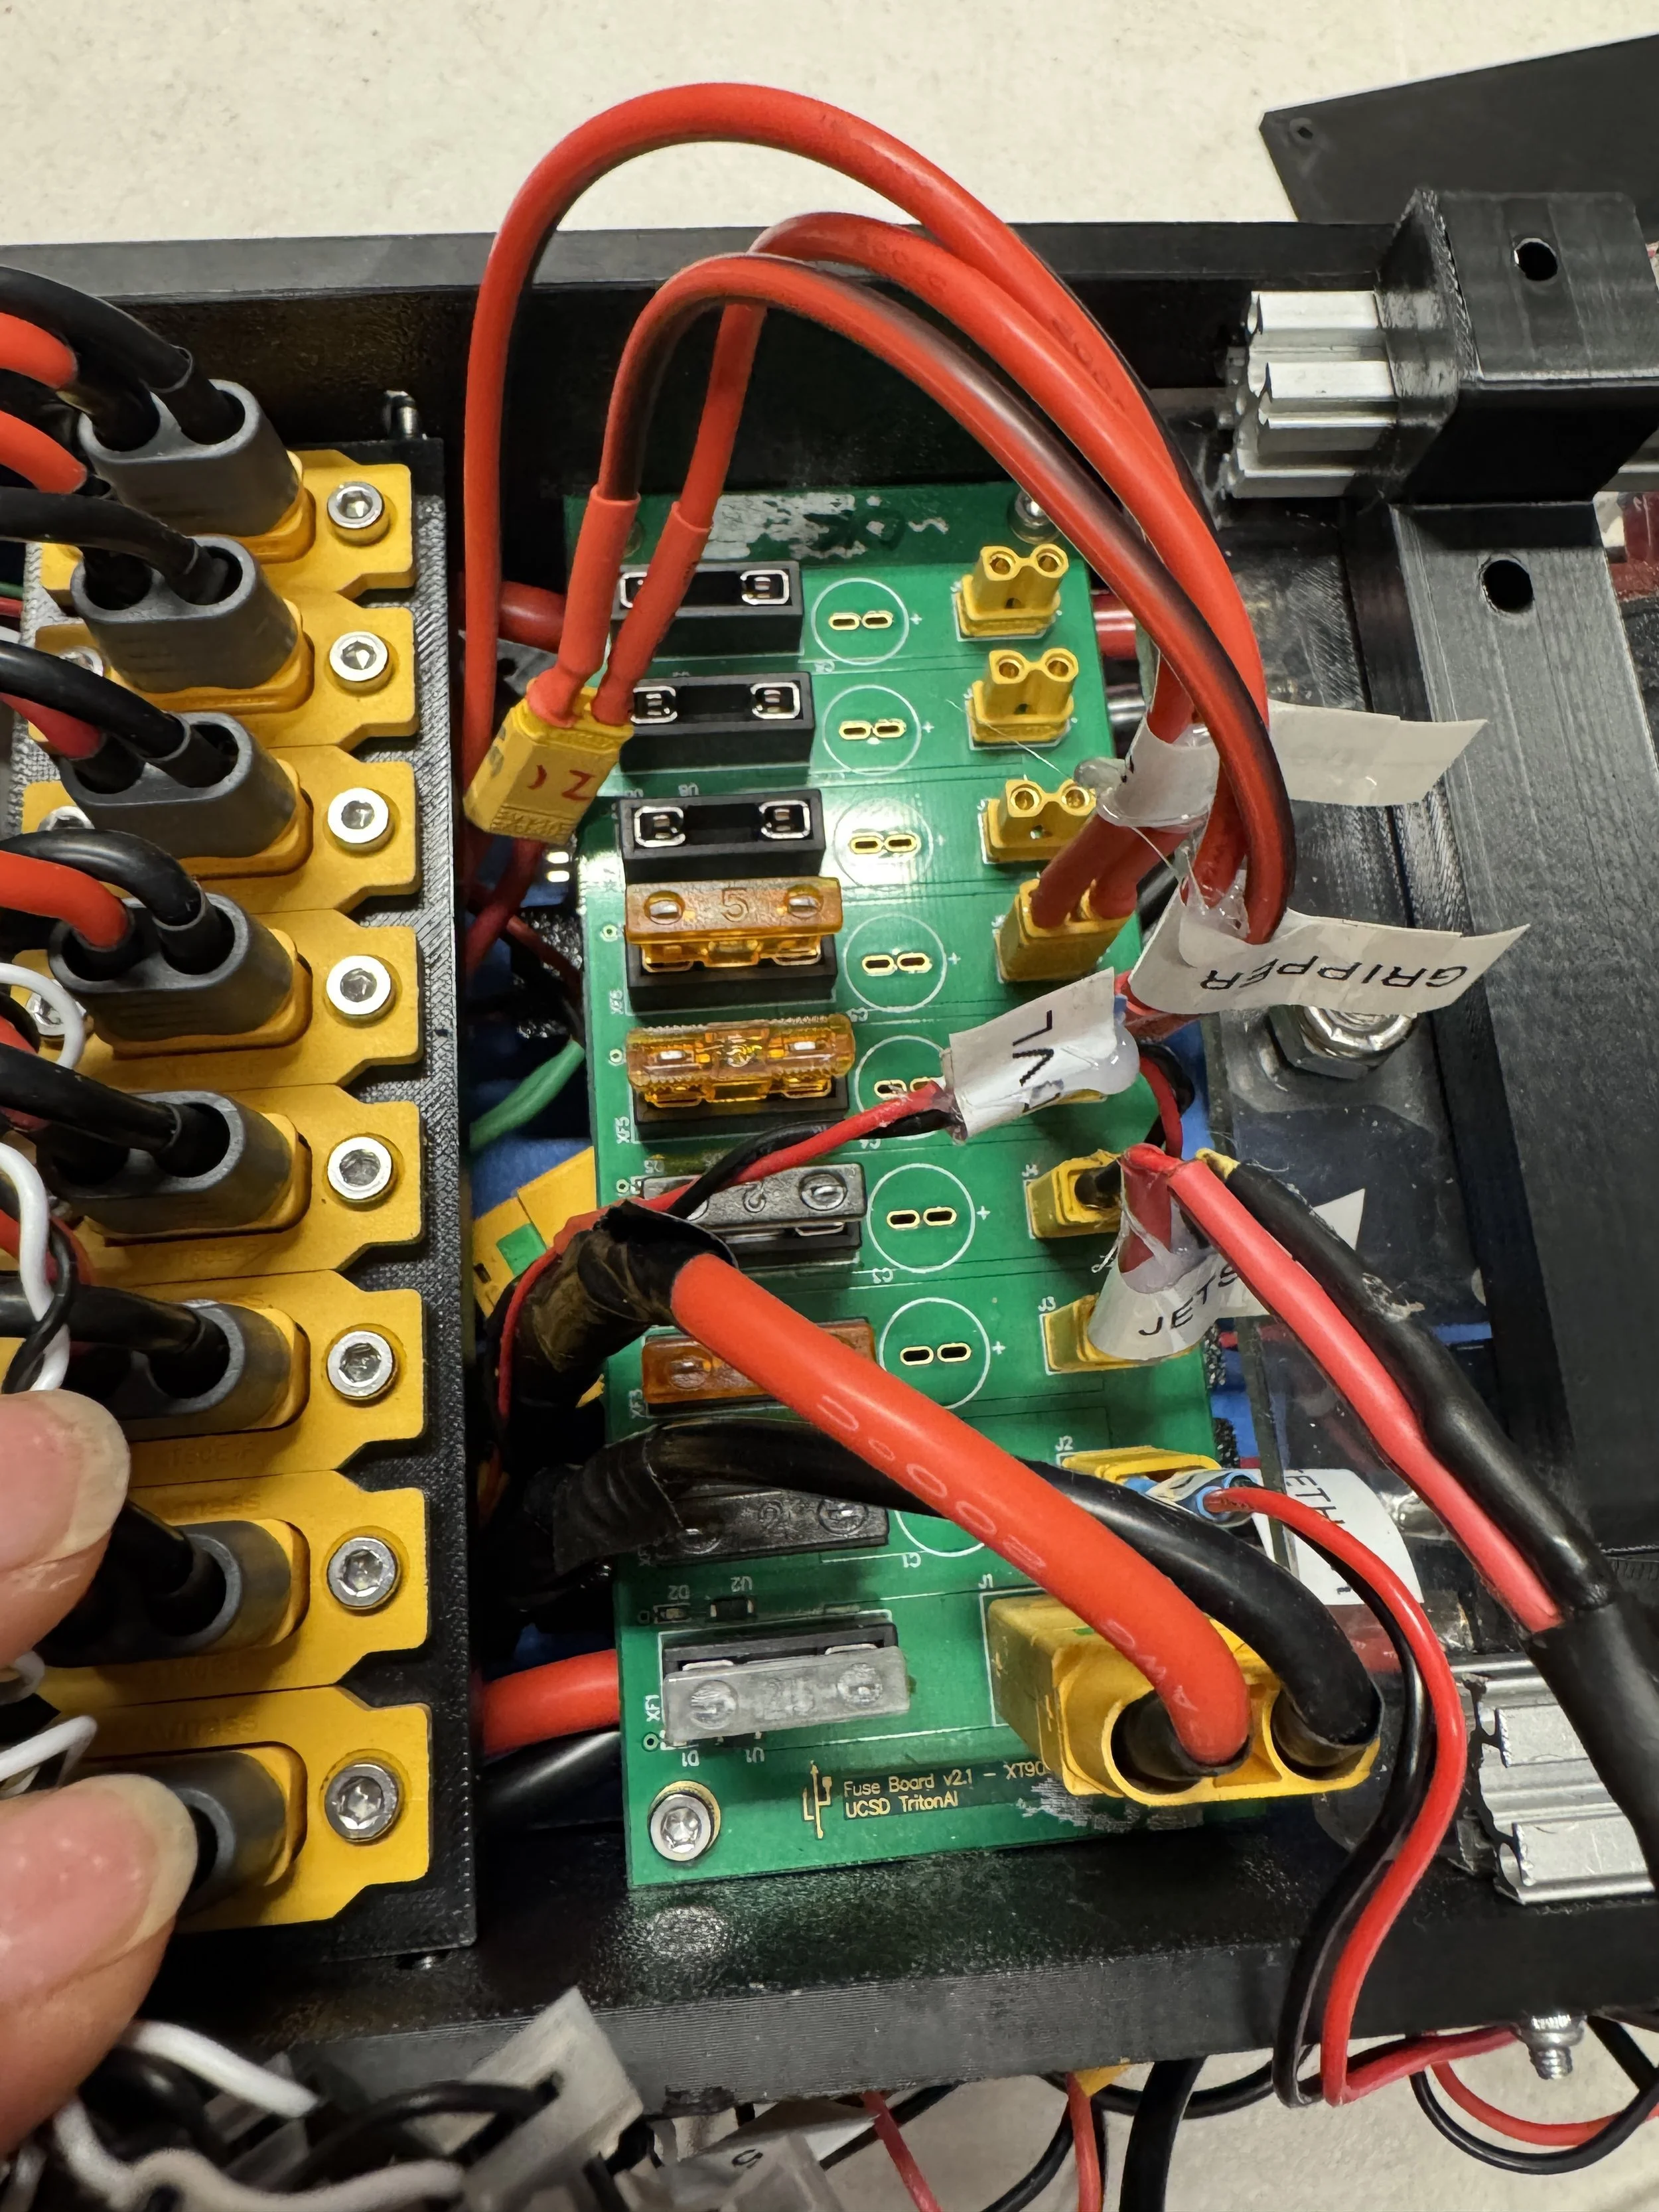
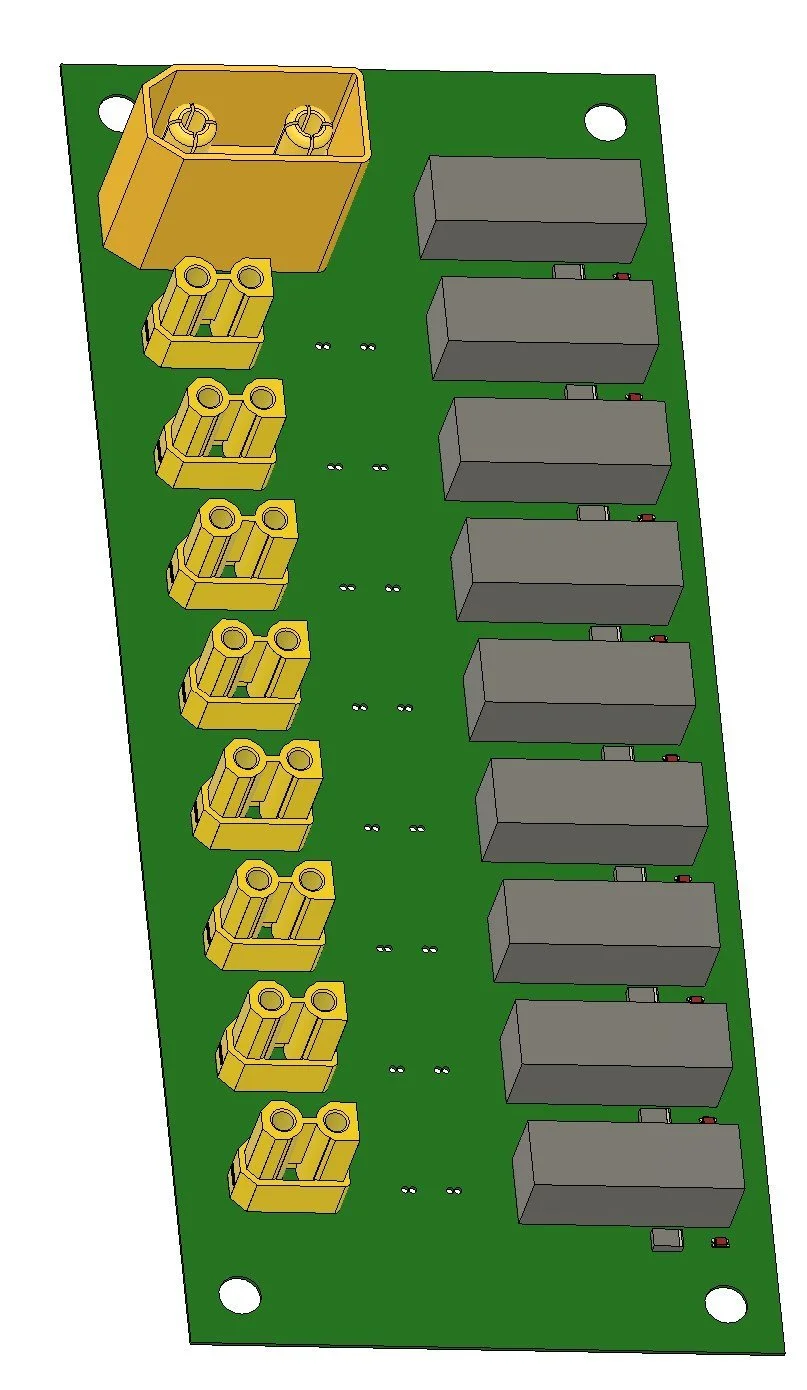
The payloads receive power from a 12VDC regulator and are distributed through a custom fuse board. The new addition of this fuse board ensures the electrical integrity of the system, just in case of a short in an individual component.