
RobotX - Sub Mechanical
RobotX 2026 > Sub Mechanical
Overview
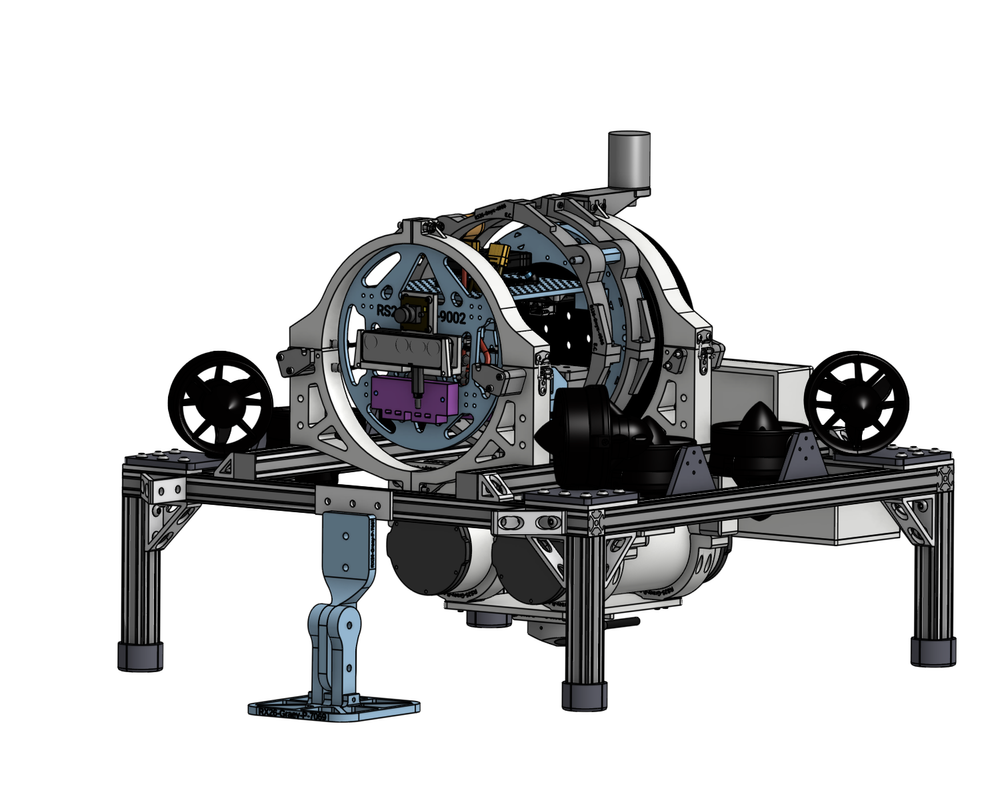
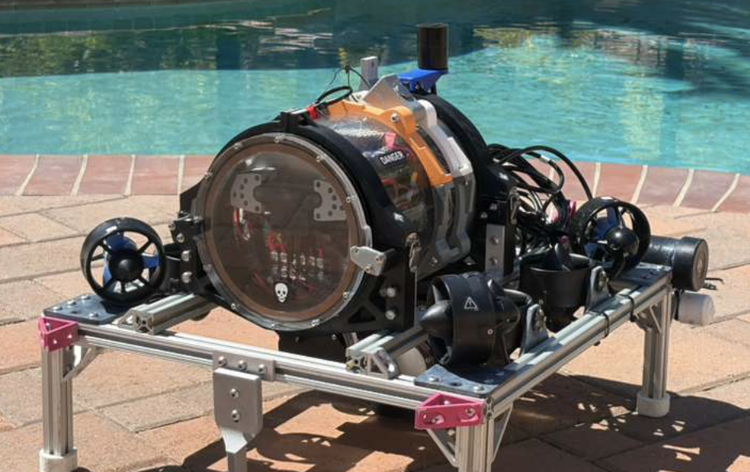
Graey
Græy (our 2020-2026 UUV) is based off Orange (our 2019-2020 UUV), so we continued to use 80/20 extrusions for the frame's base construction. Using 80/20 extrusions provides us with greater modularity in constructing our UUVs. While 80/20 extrusions may not be as compact as alternate options, like CNC waterjet parts, their quick assembly and cost efficiency allowed us to deliver within a tight schedule. Furthermore, this system’s modularity allowed us to rapidly make crucial modifications. For example, we fixed an unequally distributed buoyancy on Græy by shifting the positions of its two enclosures. With the 80/20 build system, we can use our manufacturing method of 3D printing to create accurately and properly toleranced parts that interface well.
Magnetic Light
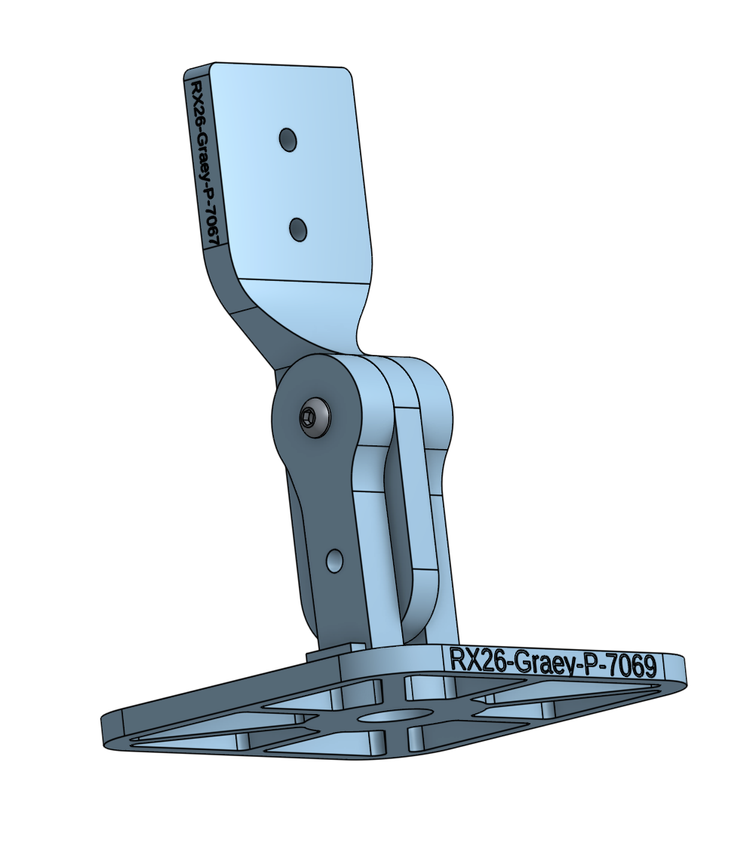
V1: first version of the magnetic light mount
Slide circle to see versions
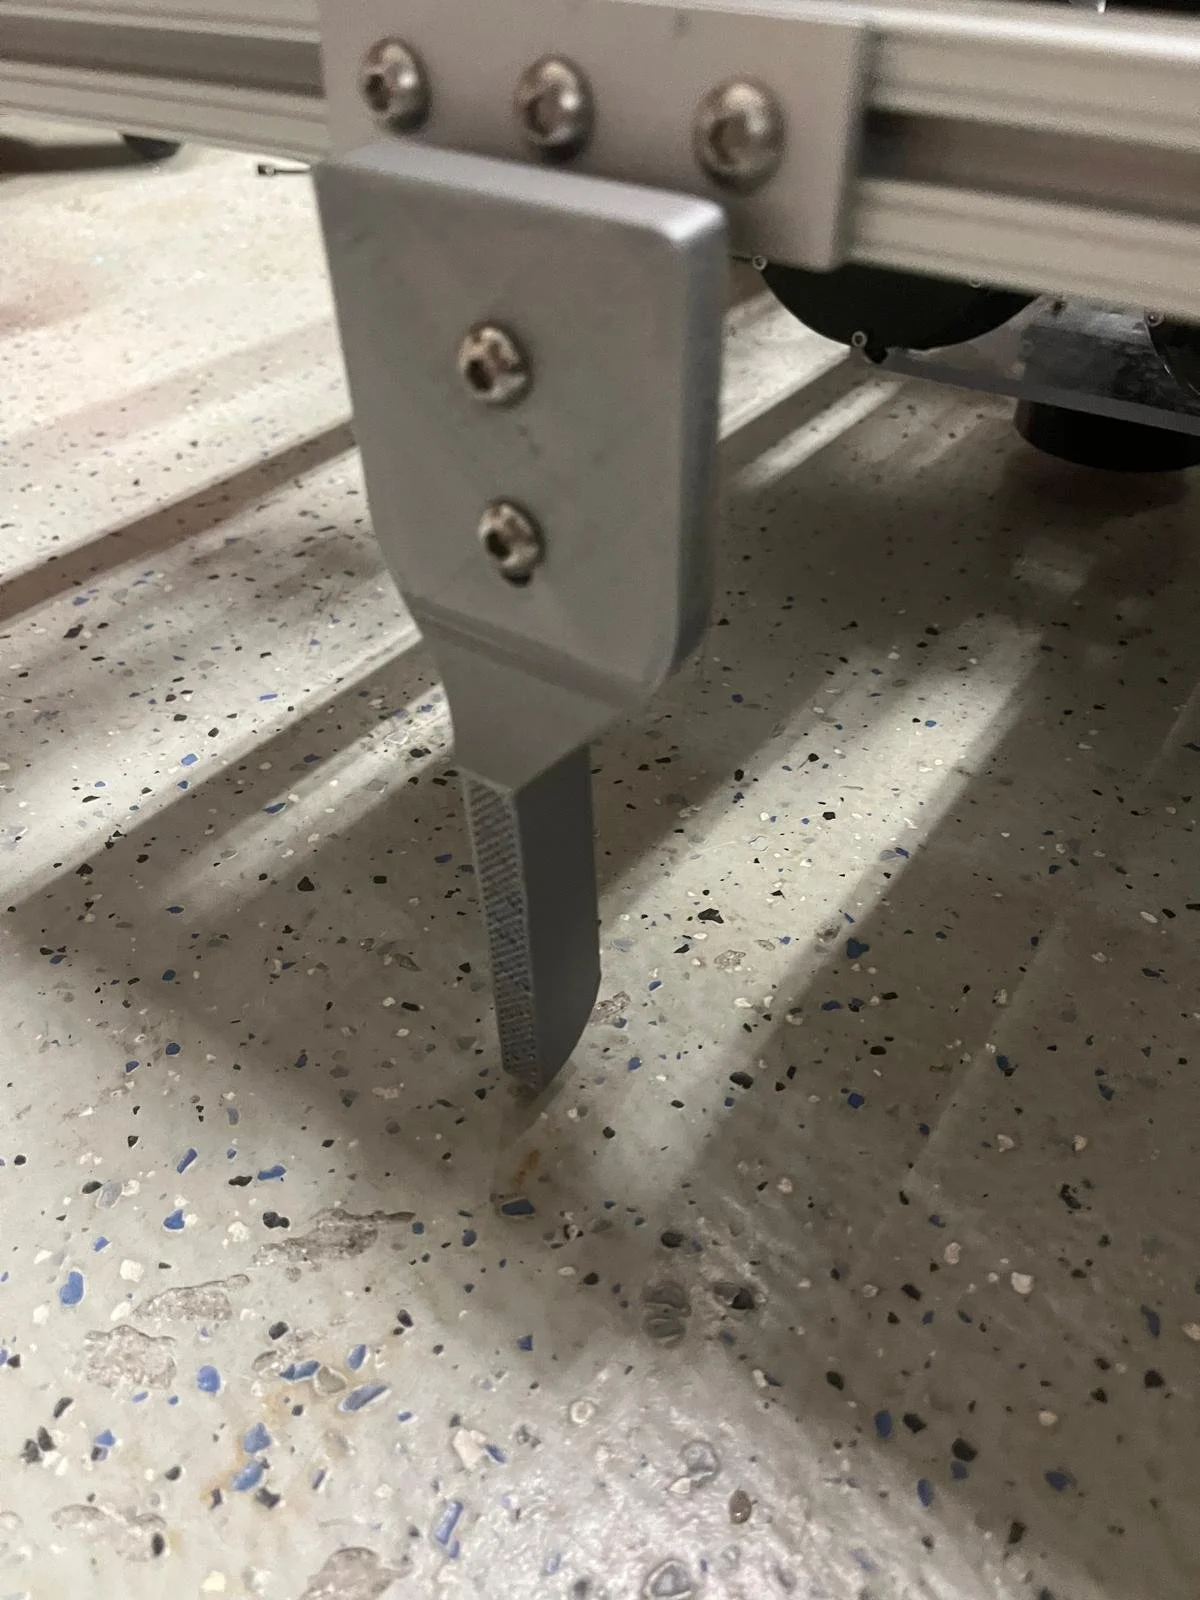
V1 broken magnetic light
For Mission Task 2: Infrastructure Survey & Repair, we use a passive joint, on the magnetic light mount. This joint doesn’t use a servo, so we can easily and freely tilt it on its own. This design attaches to the 80/20 aluminum extrusions with a T flat plate.
Kill Switch
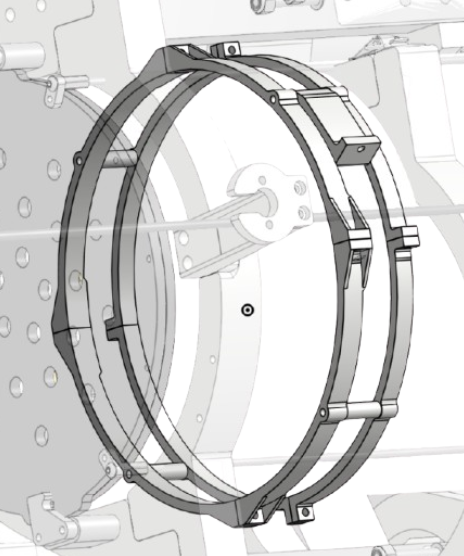
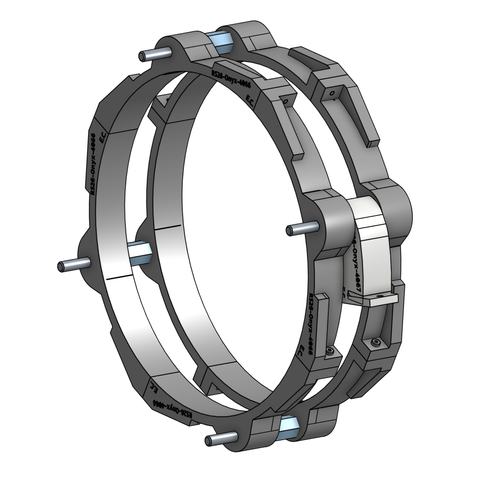
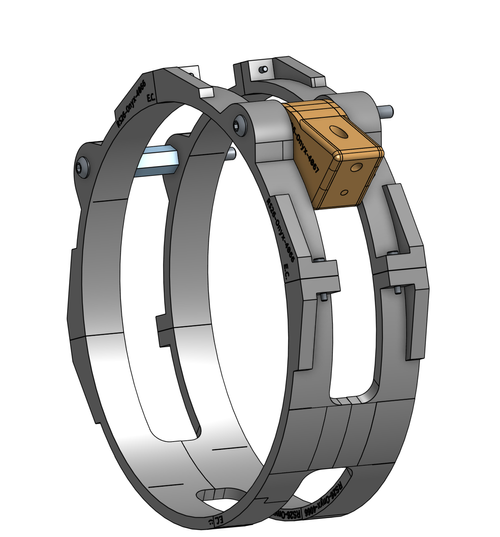
V1: After the diver pulled the kill switch during the RoboSub 2025 competition, the kill switch broke under pressure.
Slide circle to see versions
During the 2025 RoboSub Competition, our kill switch broke after the diver pulled it. To prevent this from happening again, we increased margins on our electrical kill switch system by reducing stress concentration and selecting larger fasteners. This has led to a more reliable kill switch, being able to survive the rigors of competition.
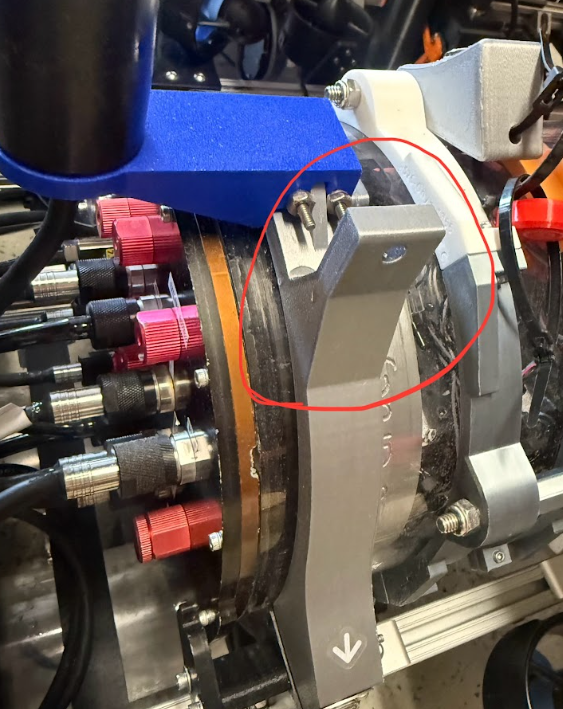
Location Beacon Mount
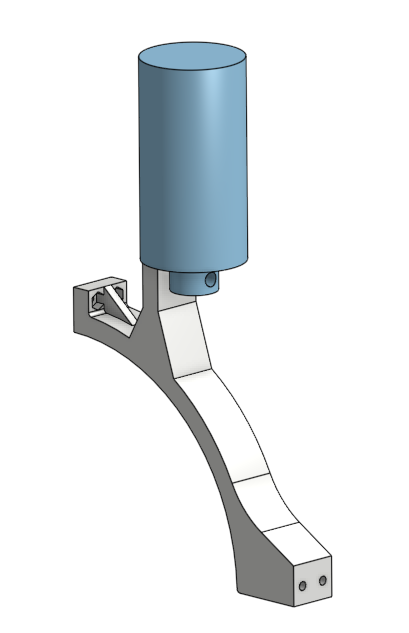
The beacon mount design prioritizes simplicity and working within inventory constraints over complicated geometry, while mitigating excessive stress resulting from drag.
Thrusters
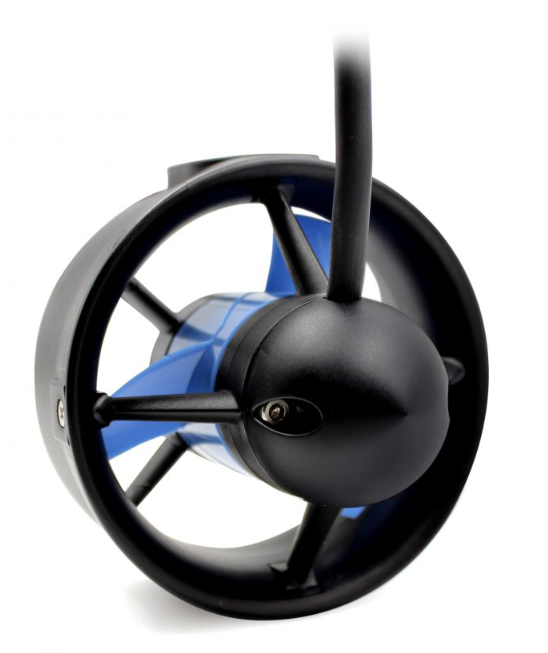
We use an 8 T200 Thrusters from Blue Robotics thruster hexagonal configuration, with thrusters placements allowing movement along all 3 directional axes (surge, sway, heave) and all three rotational axes (pitch, yaw, roll). These thrusters are mounted to the sub using laser-cut Delrin for strength.