
RobotX - Drone Mechanical
RobotX 2026 > Mechanical
Overview
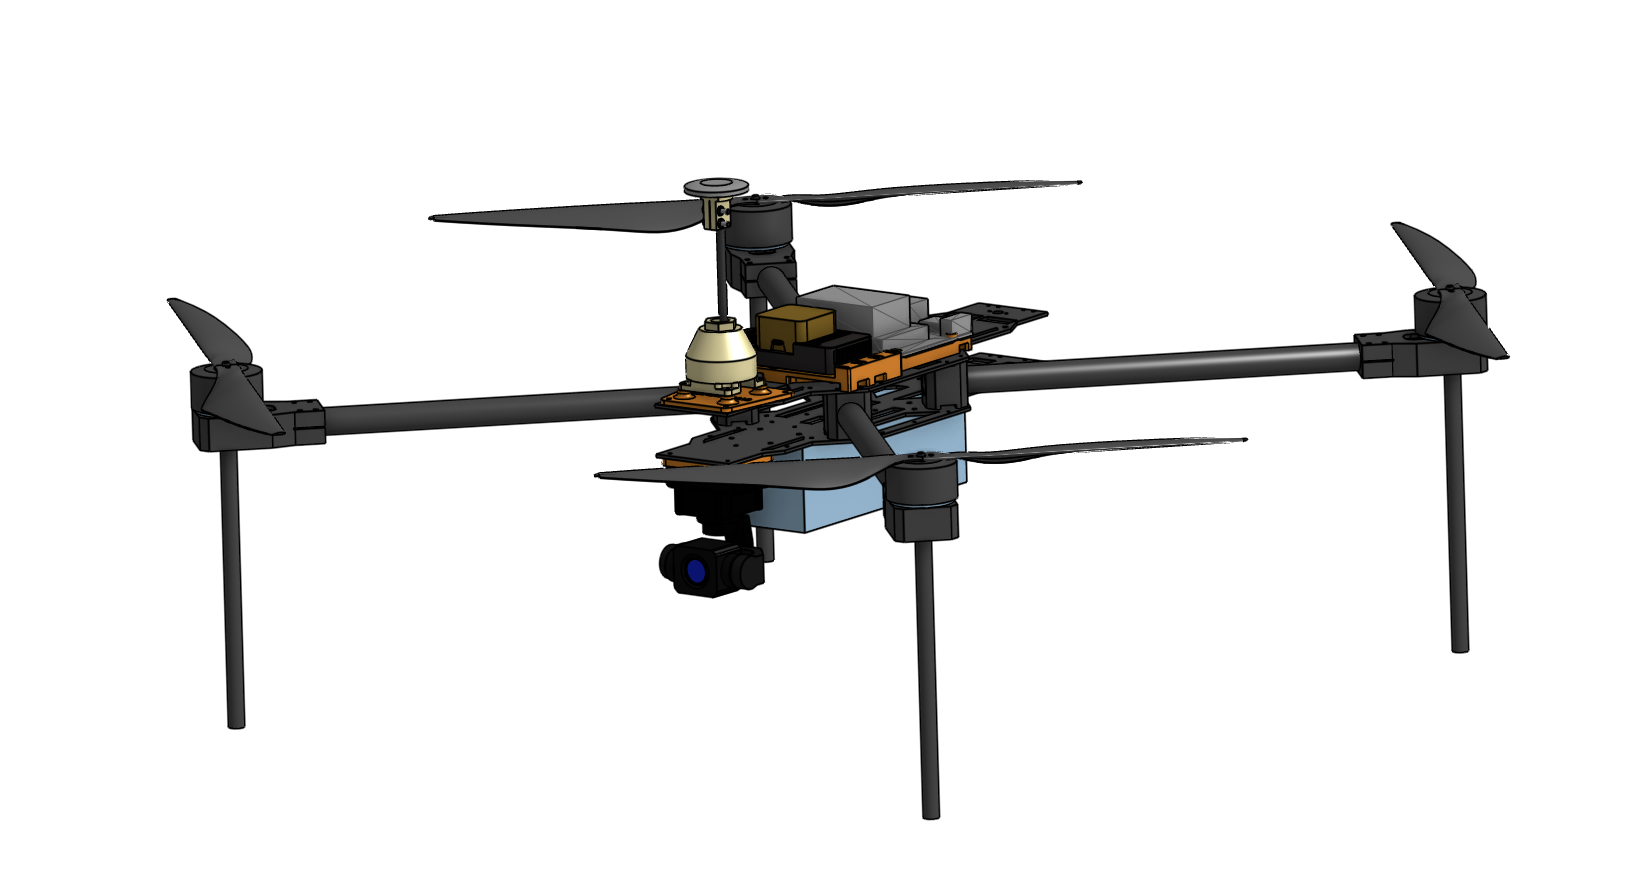
We leveraged off-the-shelf drone frames, such as the Tarot 650, to allow resources to be focused on electrical integration and flight testing rather than custom frame fabrication. Through iterative improvement, we pivoted between several drone frames, building multiple configurations to test different components before standardizing on a single design and aggregating spares.
Magnetically Activated Gripper
The gripper uses a switchable neodymium magnet actuated by a GoBilda 2000 Series torque servo. The servo rotates the magnet's control knob to toggle the magnetic field on and off, allowing the gripper to engage and release the tin without needing continuous power to hold the tin. The current design is fairly heavy (233g) , so in the future we would like to reduce its overall weight, use a larger magnet, and add a waterproof enclosure for the servo.
Propulsion System
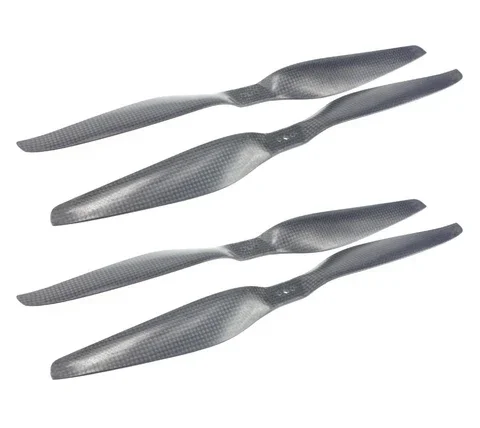
Don has 4 14in propellers while Ekko has 16in carbon fiber propellers. The propellers use MAD 4014 IPE motors with the Pixhawk Cube Orange+ flight controller. The propellers are different to match the different frame sizes. Don uses a smaller Tarot IRON MAN 650 frame while Ekko uses a bigger 9IMOD IDF-17 frame. We are considering using 16in propellers for Ekko, which will create a change in thrust (which increases our Maximum Take Off Mass → MTOM)