
RobotX 2026 > Drone
Drone (UAV)
Overview
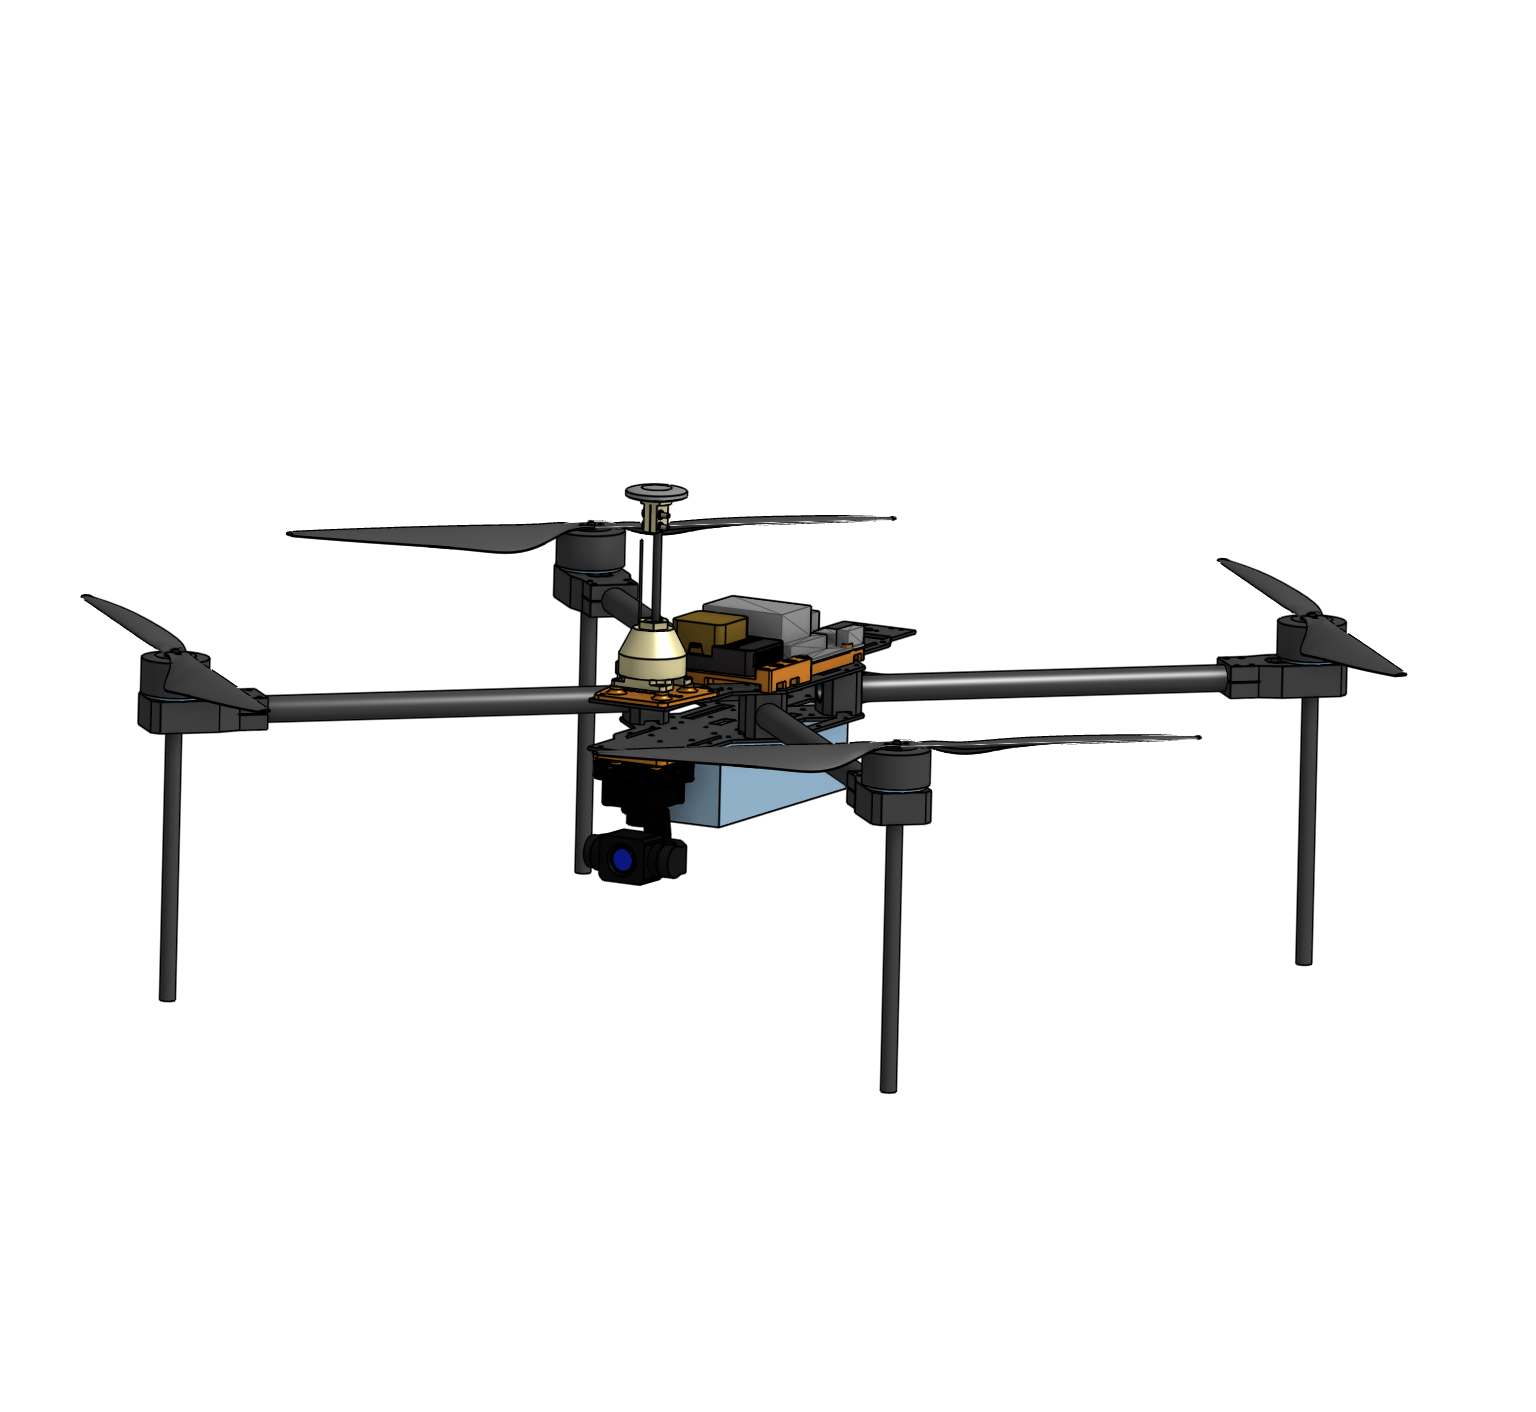
The team prepared two different vehicles, as well as two vehicles of each configuration, for four UAVs in total since crashing does happen. This allows us for parallel prototyping and development as well as un-interrupted testing — when one drone is flying, another drone is being upgraded.
Don
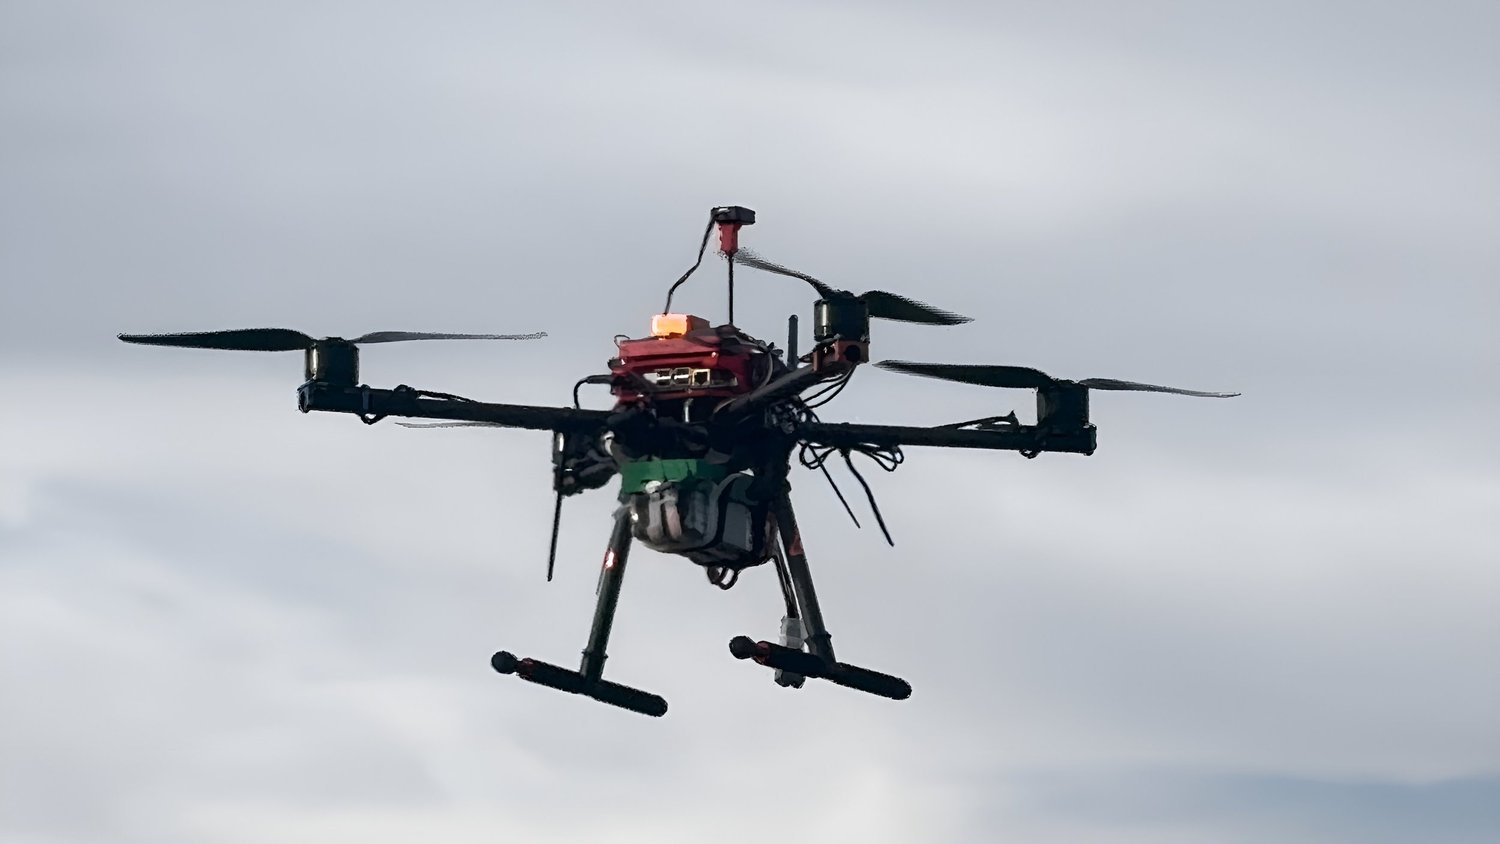
Weight
2.99kg/ 6.59 lbs
Top Speed
3 m/s
Degrees of Freedom
3 Translational (Longitude, Latitude, Altitude)
3 Rotational (Roll, Pitch, Yaw)
Dimensions
.5m x .5m x. 4.4m
Endurance
12 minutes
Wireless Communications
Wifi
RFD900ux modem
Remote ID
Power System
Tattu 16000 mAh Lipo 6s1P Battery
Main Processor
Jetson Orin Nano
Propulsion System
4014 IPE Drone Motor 370KV/400KV (x4)
14-Inch Carbon Fiber Prop Propeller 1455 (x4)
Navigation System
Pixhawk Orange Cube
Centimeter Precision GPS RTK
Software Architecture
Robot Operating System (ROS 2 Humble)
Perception Sensors
SIYI A8 mini camera
Ekko
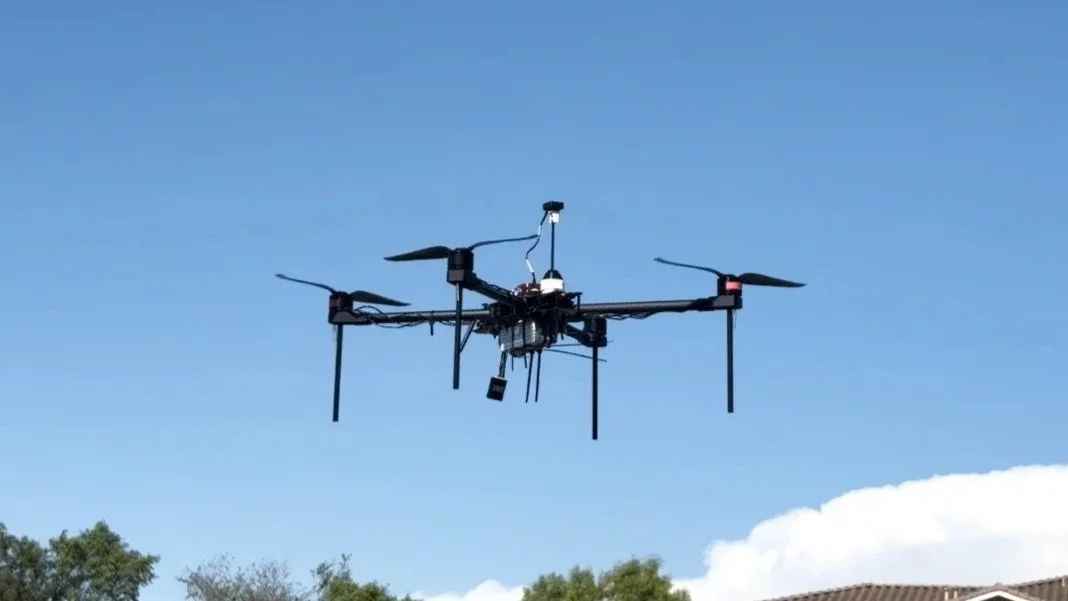
Weight
4.40kg/ 9.7 lbs
Top Speed
4 m/s
Degrees of Freedom
3 Translational (Longitude, Latitude, Altitude)
3 Rotational (Roll, Pitch, Yaw)
Dimensions
.61m x .6m x .39m
Endurance
20 minutes
Wireless Communications
Wifi
RFD900ux modem
Remote ID
Power System
Tattu 16000 mAh 6s1P Lipo Battery
Main Processor
Jetson Orin Nano
Propulsion System
4014 IPE Drone Motor 370KV/400KV (x4)
16-Inch Carbon Fiber Propeller (x4)
Navigation System
Pixhawk Orange Cube
Centimeter Precision GPS RTK
Software Architecture
Robot Operating System (ROS 2 Humble)
Perception Sensors
SIYI A8 mini camera