
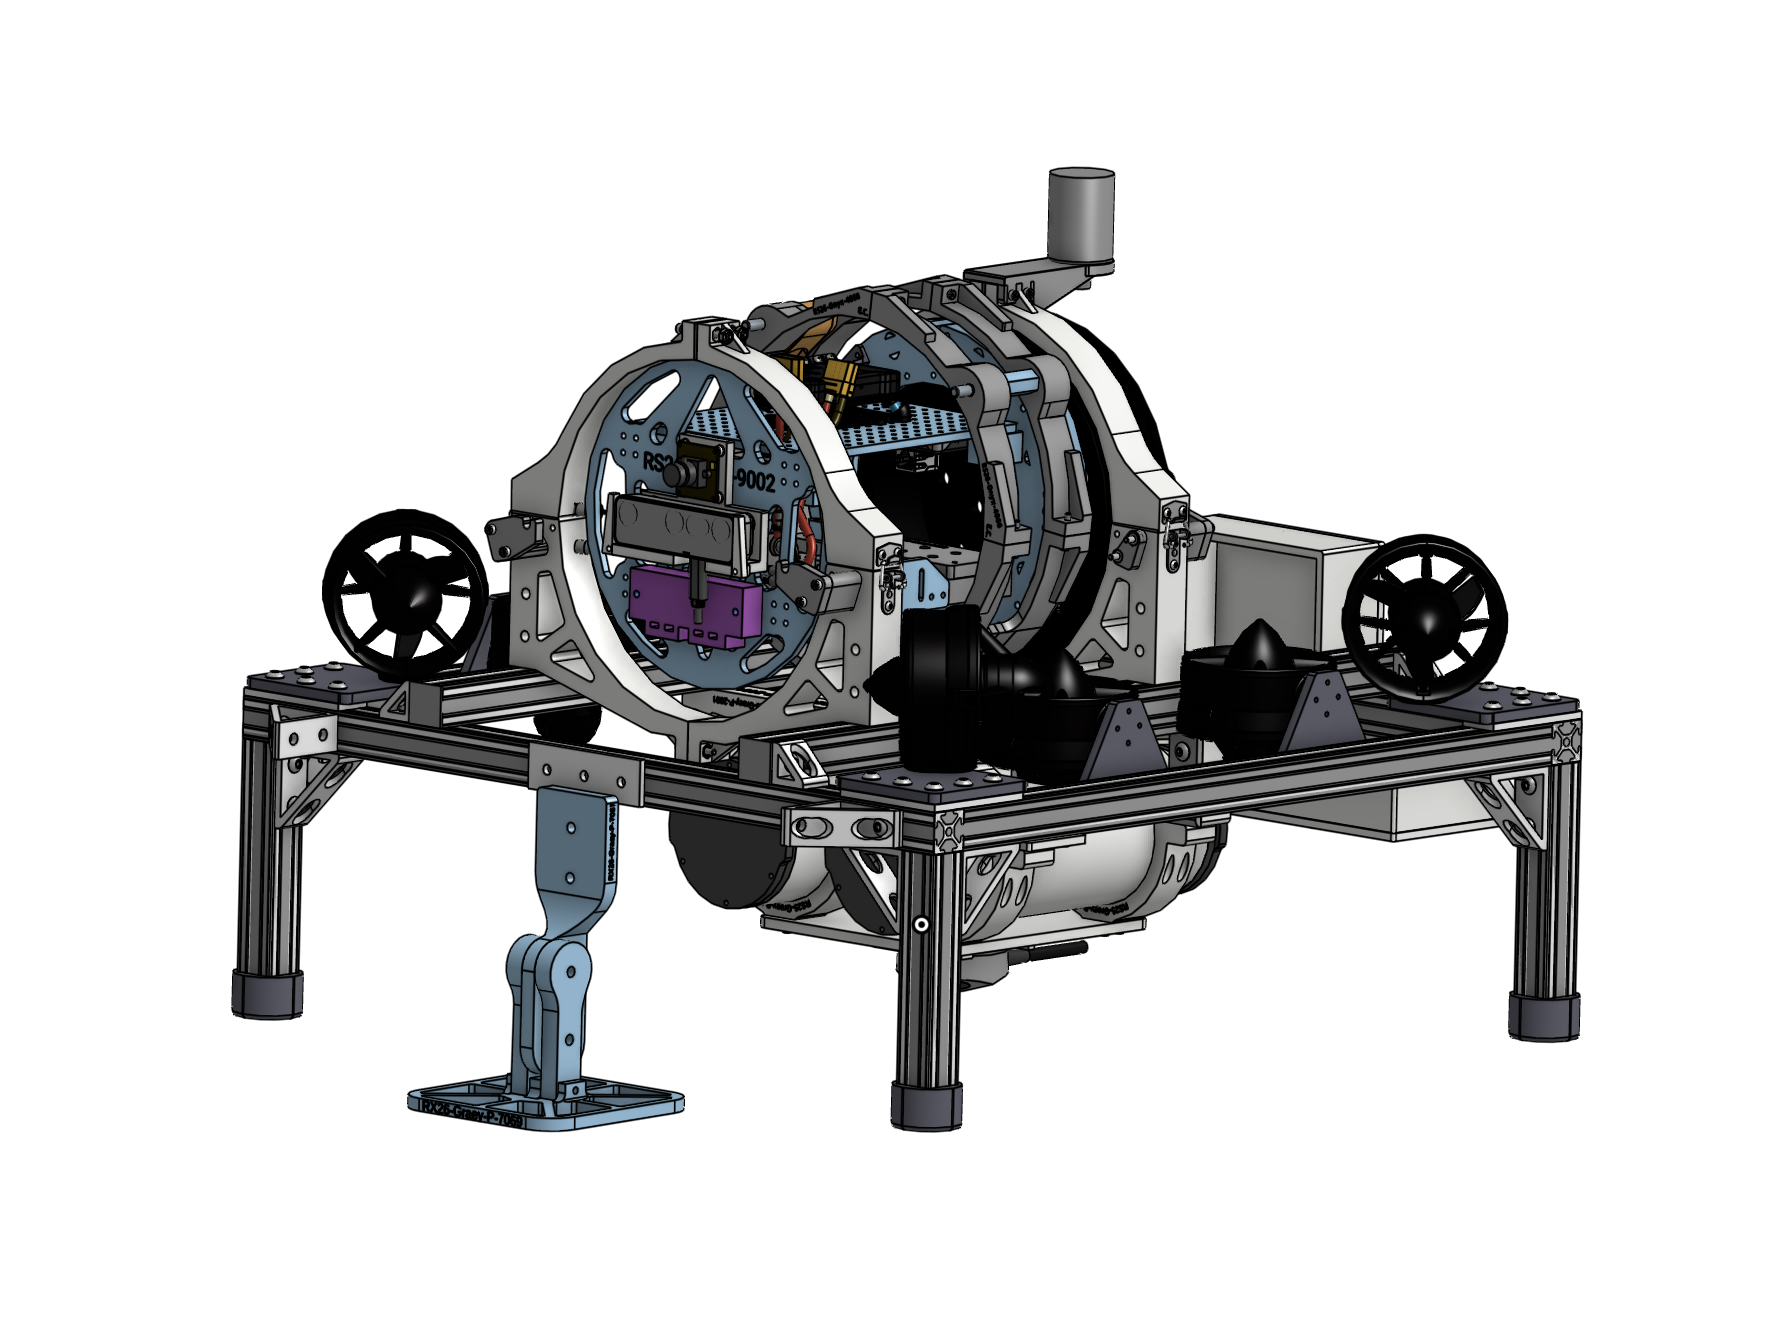
RobotX 2026 > Sub (UUV)
Sub (UUV)
Overview
Our sub, Graey, features an 8-thruster holonomic layout using 80/20 aluminum extrusion frames. We’ve learned that simplicity and modularity are the best practices. We have aligned our hull with the center of mass, and used PVC pipes to adjust bouyancy. Additionally, we use interconnect and a double layer of O-rings for reliable waterproofing.
Græy
Graey Proof of Readiness Submission
Weight
With 2 Batteries: 51.08 lbs
Degrees of Freedom
3 translational (x,y,z)
3 rotational (roll, pitch, yaw)
Power System
Lithium-ion battery 14.8V, 15.6Ah(2x)
Wireless Communications
Succorfish Delphis modem
Wifi
Dimensions
22”w x 22”l x 16”h
Endurance
Normal usage: 1 hour runtime
Main Processor
Jetson Orin Nano
Propulsion System
T200 thruster (x8)
Full throttle FWD/REV thrust @ nominal (16V) 11.6 / 9.0 lb f
Sensors
SIDUS SS400 Camera (x2)
Oak-D Camera (x2)
Ping 360 Sonar
Navigation System
VectorNav VN-100 IMU/AHRS
Pixhawk orange cube
Waterlinked DVL
Software Architecture
Robot Operating System 2 Humble (ROS2)